119 launches · 252 suppliers · updated 2026-10-20
The launch feed for embodied AI.
New robots, modules and models from official sources, linked to the suppliers behind them.
Featured launches
 Featured
Sharpa W02 Dexterous Hand
Sharpa · 2026-09-24
 Featured
Unitree Dex5-S Dexterous Hand
Unitree Robotics · 2026-09-21
 Featured
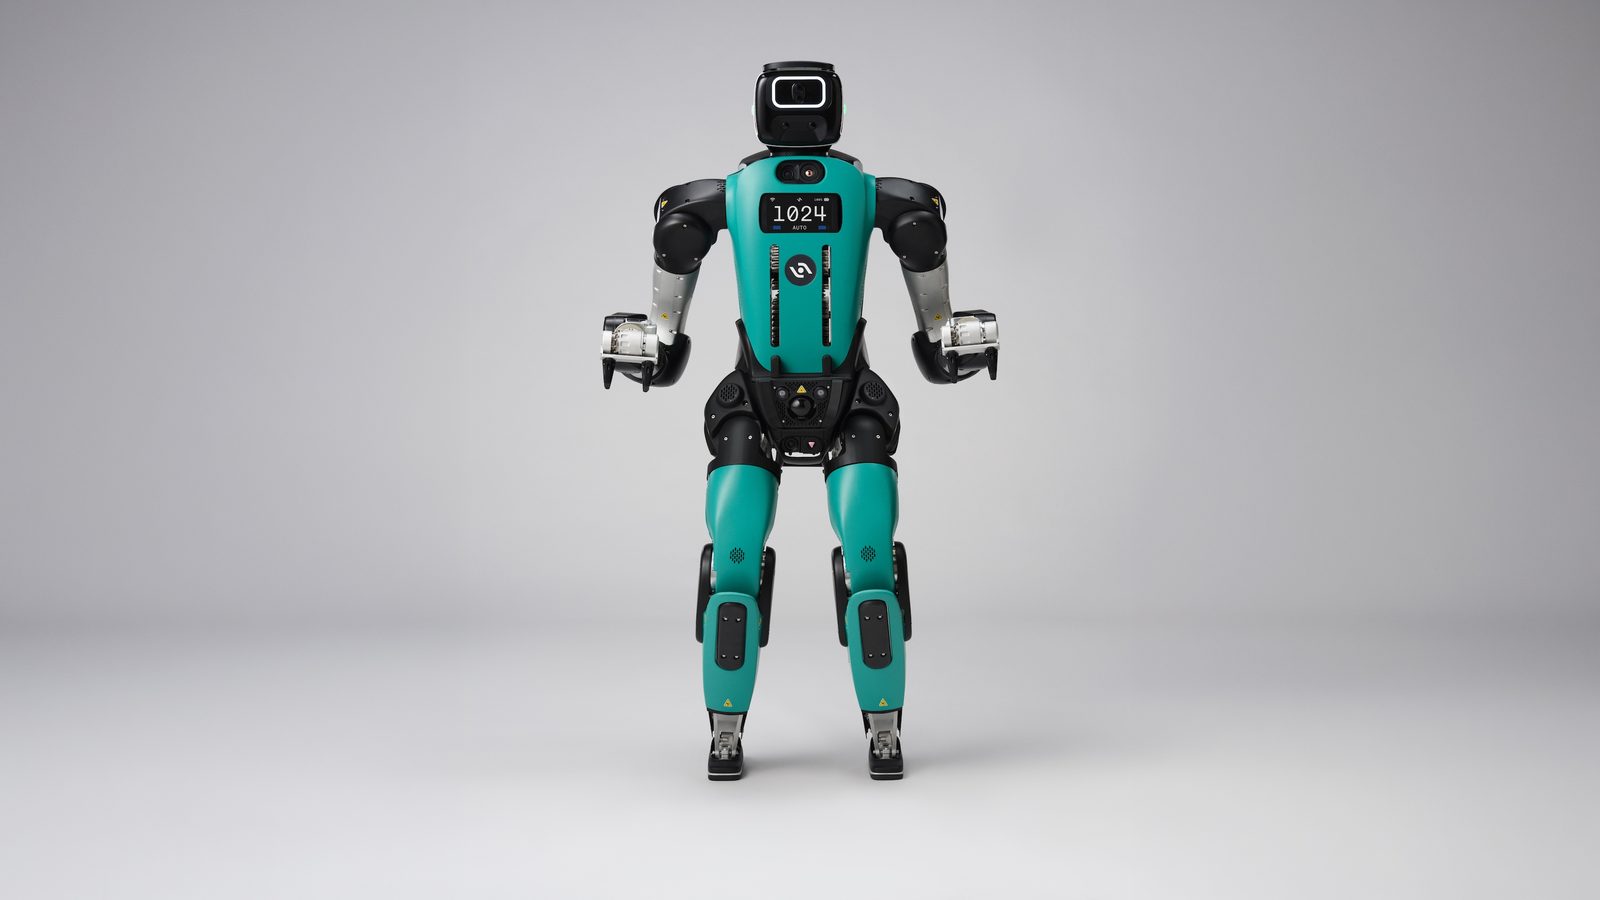
Agility Digit 5
Agility Robotics · 2026-09-15
 Featured
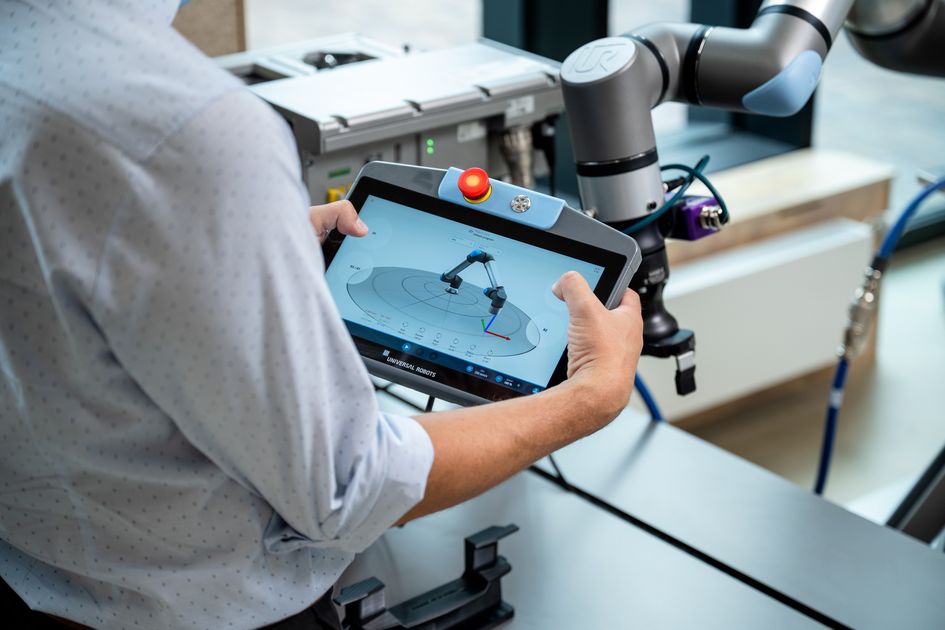
Universal Robots Gen 7
Universal Robots (Teradyne Robotics) · 2026-09-14
 Featured
Gemini Robotics 2
Google DeepMind · 2026-07-30
 Featured
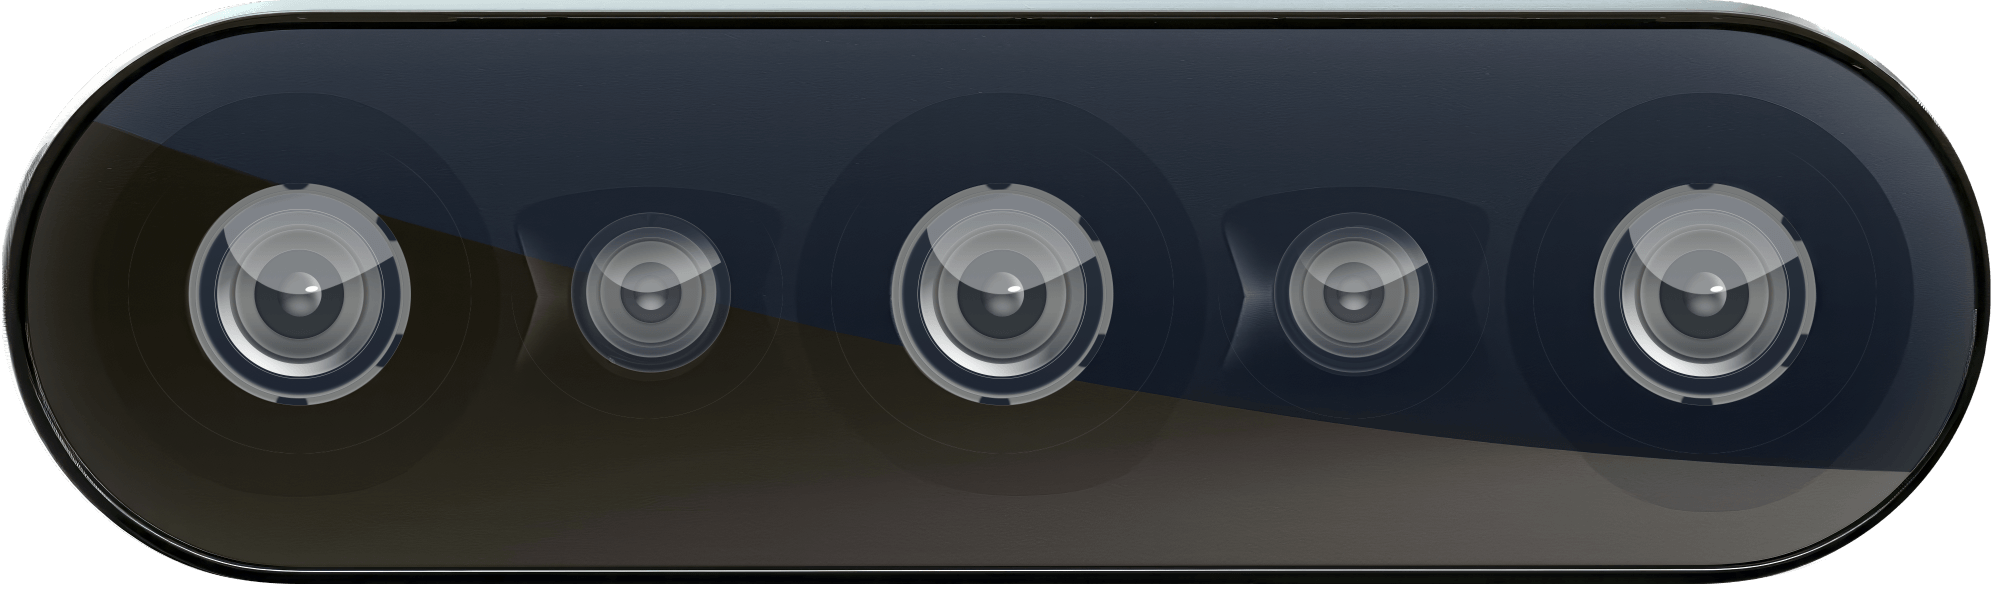
RealSense D585 Pro
RealSense · 2026-06-18
 Featured
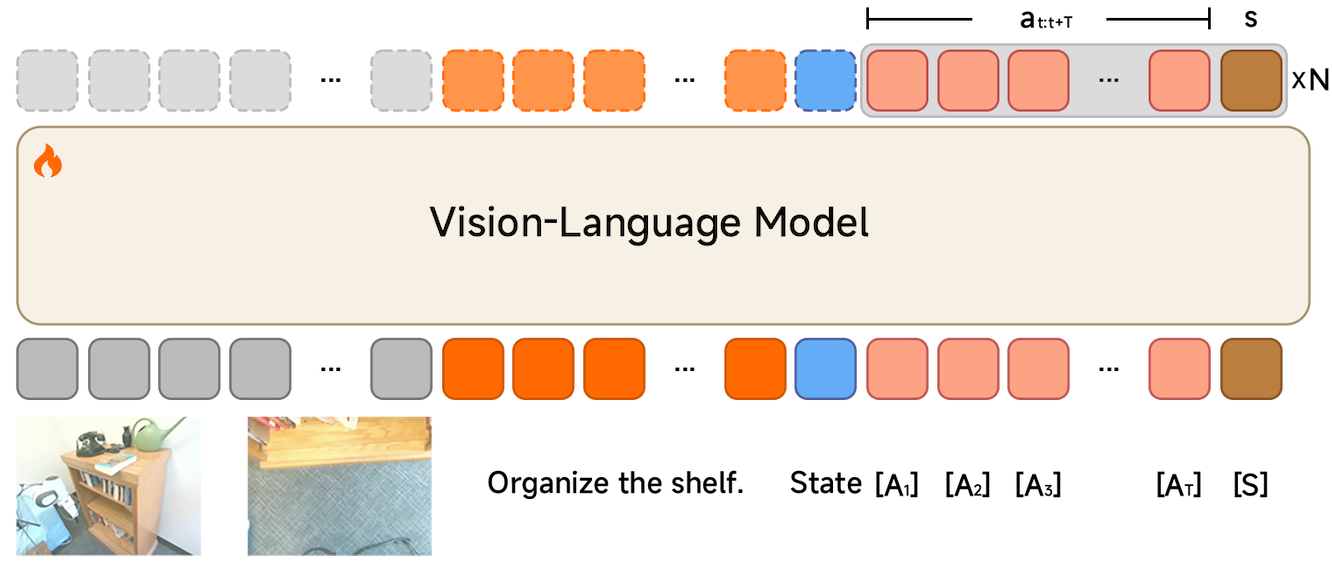
Xiaomi-Robotics-0
Xiaomi · February 2026
 Featured
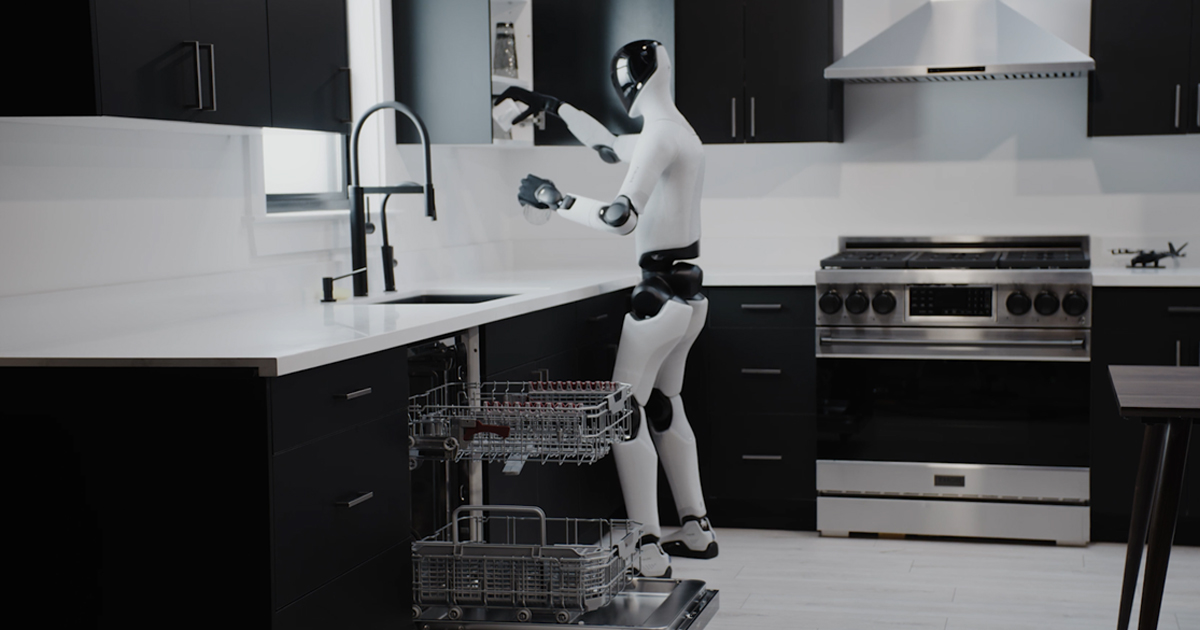
Figure Helix 02
Figure AI · 2026-01-27
 Featured
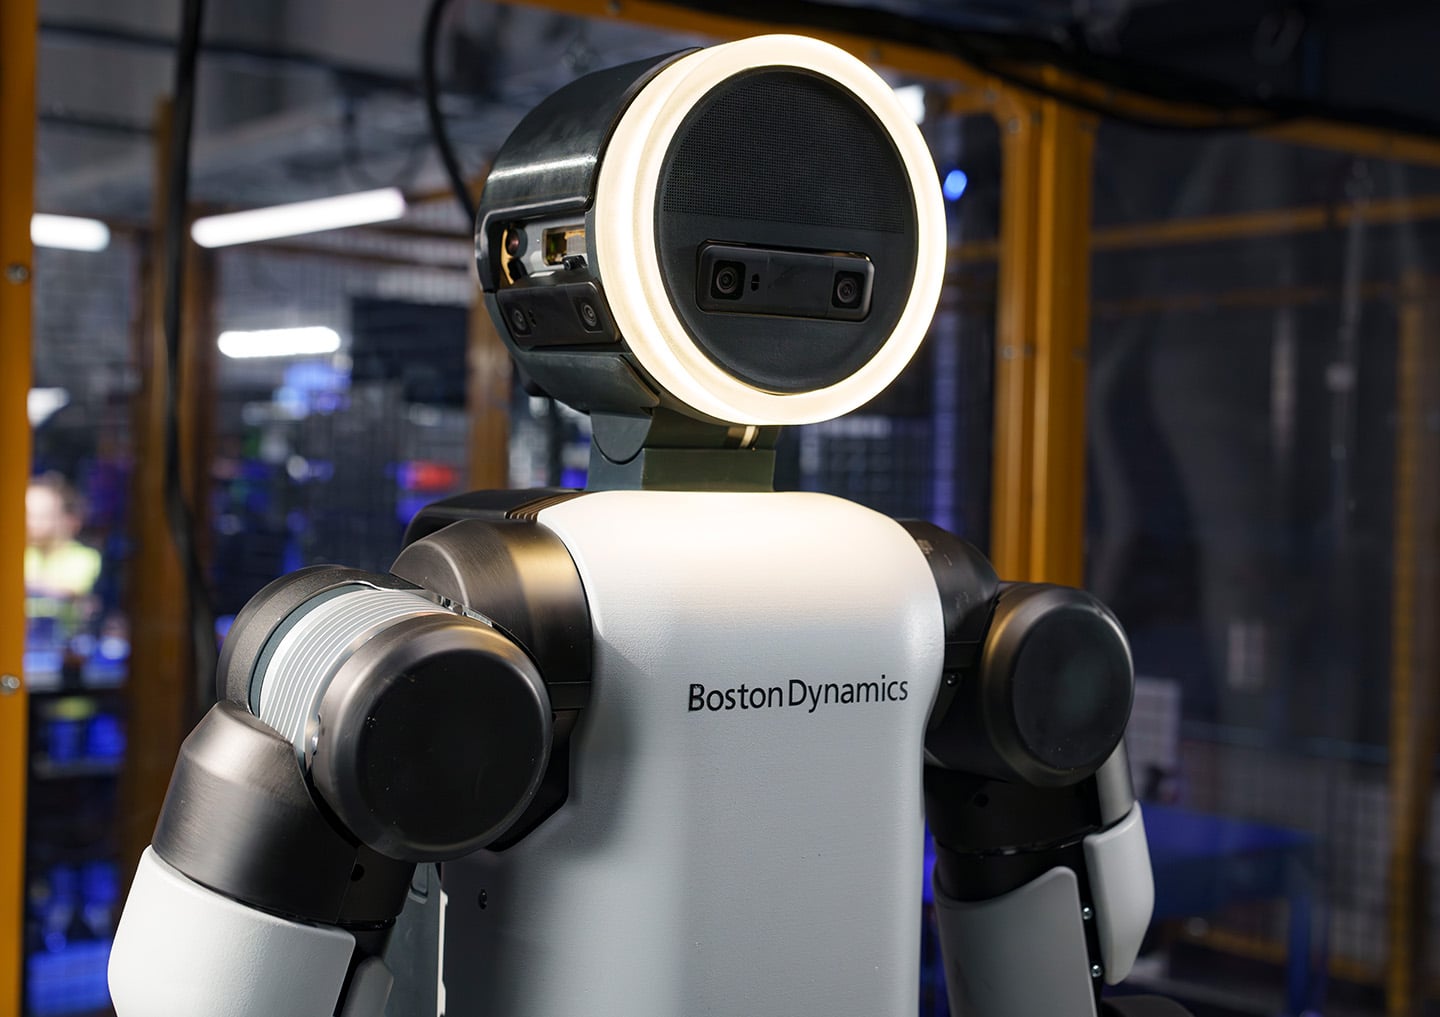
Boston Dynamics Atlas
Boston Dynamics · 2026-01-05
 Featured
NVIDIA Isaac GR00T N1.6
NVIDIA · 2026-01-05
 Featured
π*0.6
Physical Intelligence · 2025-11-18
 Featured
1X NEO Home Robot
1X Technologies · 2025-10-28
All launches

Mobile manipulation solution that pairs the PiPER-X arm with the GENISOM M1 platform, which AgileX says won the IROS 2026 championship.

Swarm control system for choreographing robot formations, monitoring device status in real time and safety braking.


High-speed collaborative arm series for demanding industrial applications, with 7 m/s peak TCP speed and 30+ safety functions; shown at CIIF 2026.

Tactile sensor that lets a robot recognize and retrieve objects without vision by feeling pressure, texture, vibration, slip and temperature.

Ultra-compact embedded 6-axis arm designed to build robotic capability into compact equipment.

Beta API opening access to Physical Intelligence's models so more teams can adapt them to their robots and applications.


All-in-one dual-arm development platform with isomorphic teleoperation, multimodal data collection and an open toolchain; now open for orders.
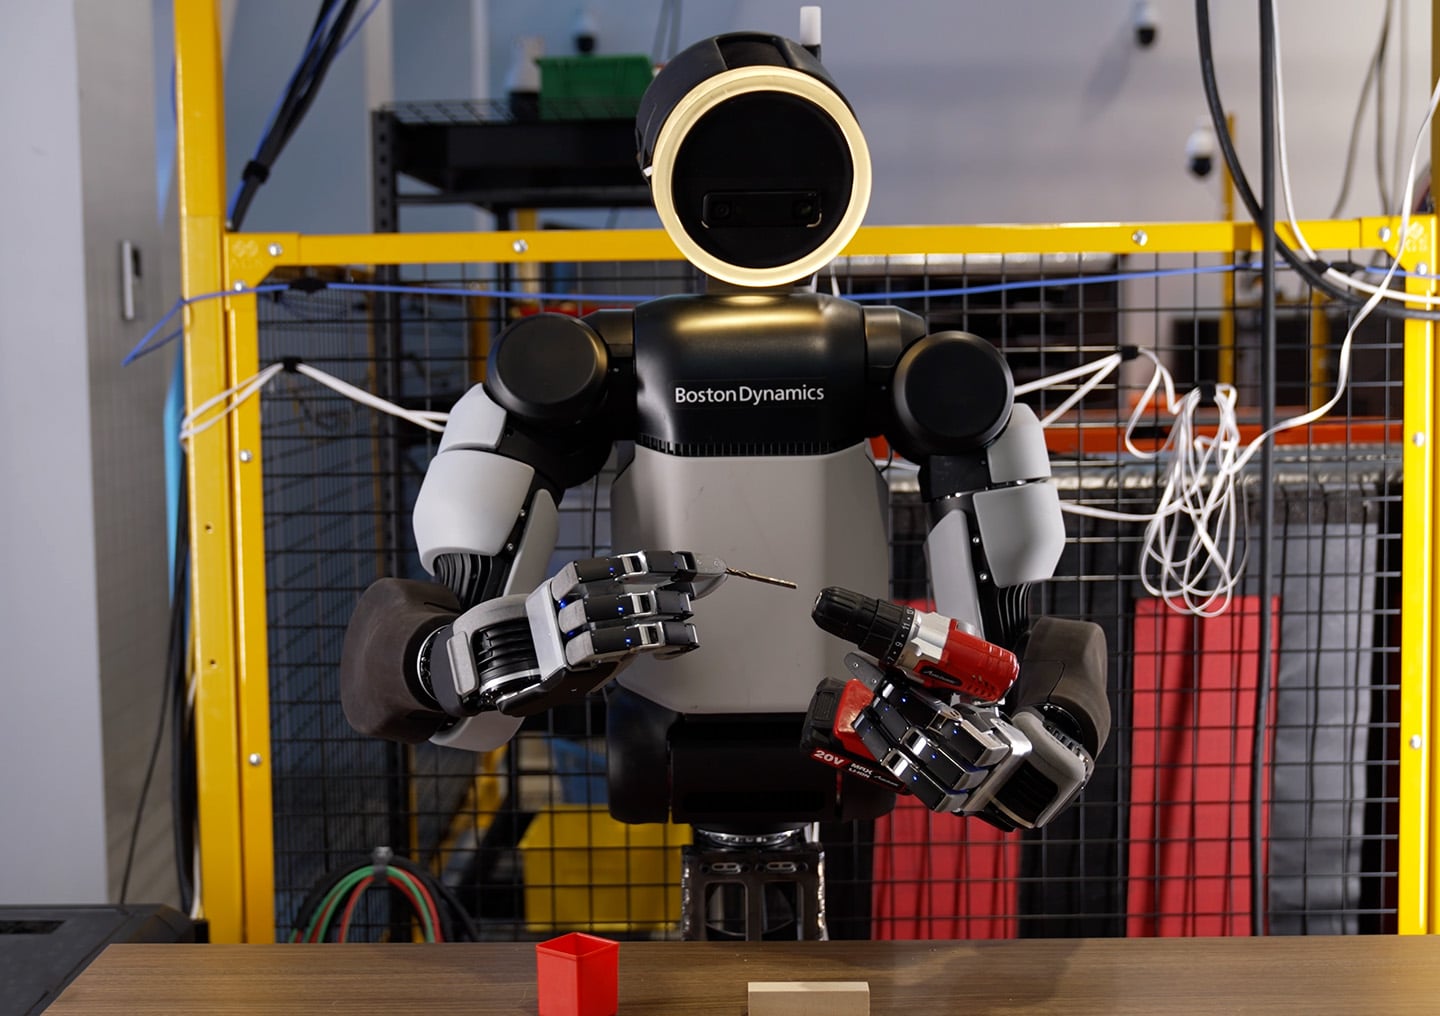
New 13-degree-of-freedom, directly actuated hands for the Atlas humanoid, designed for high-fidelity simulation and sim-to-real reinforcement learning.
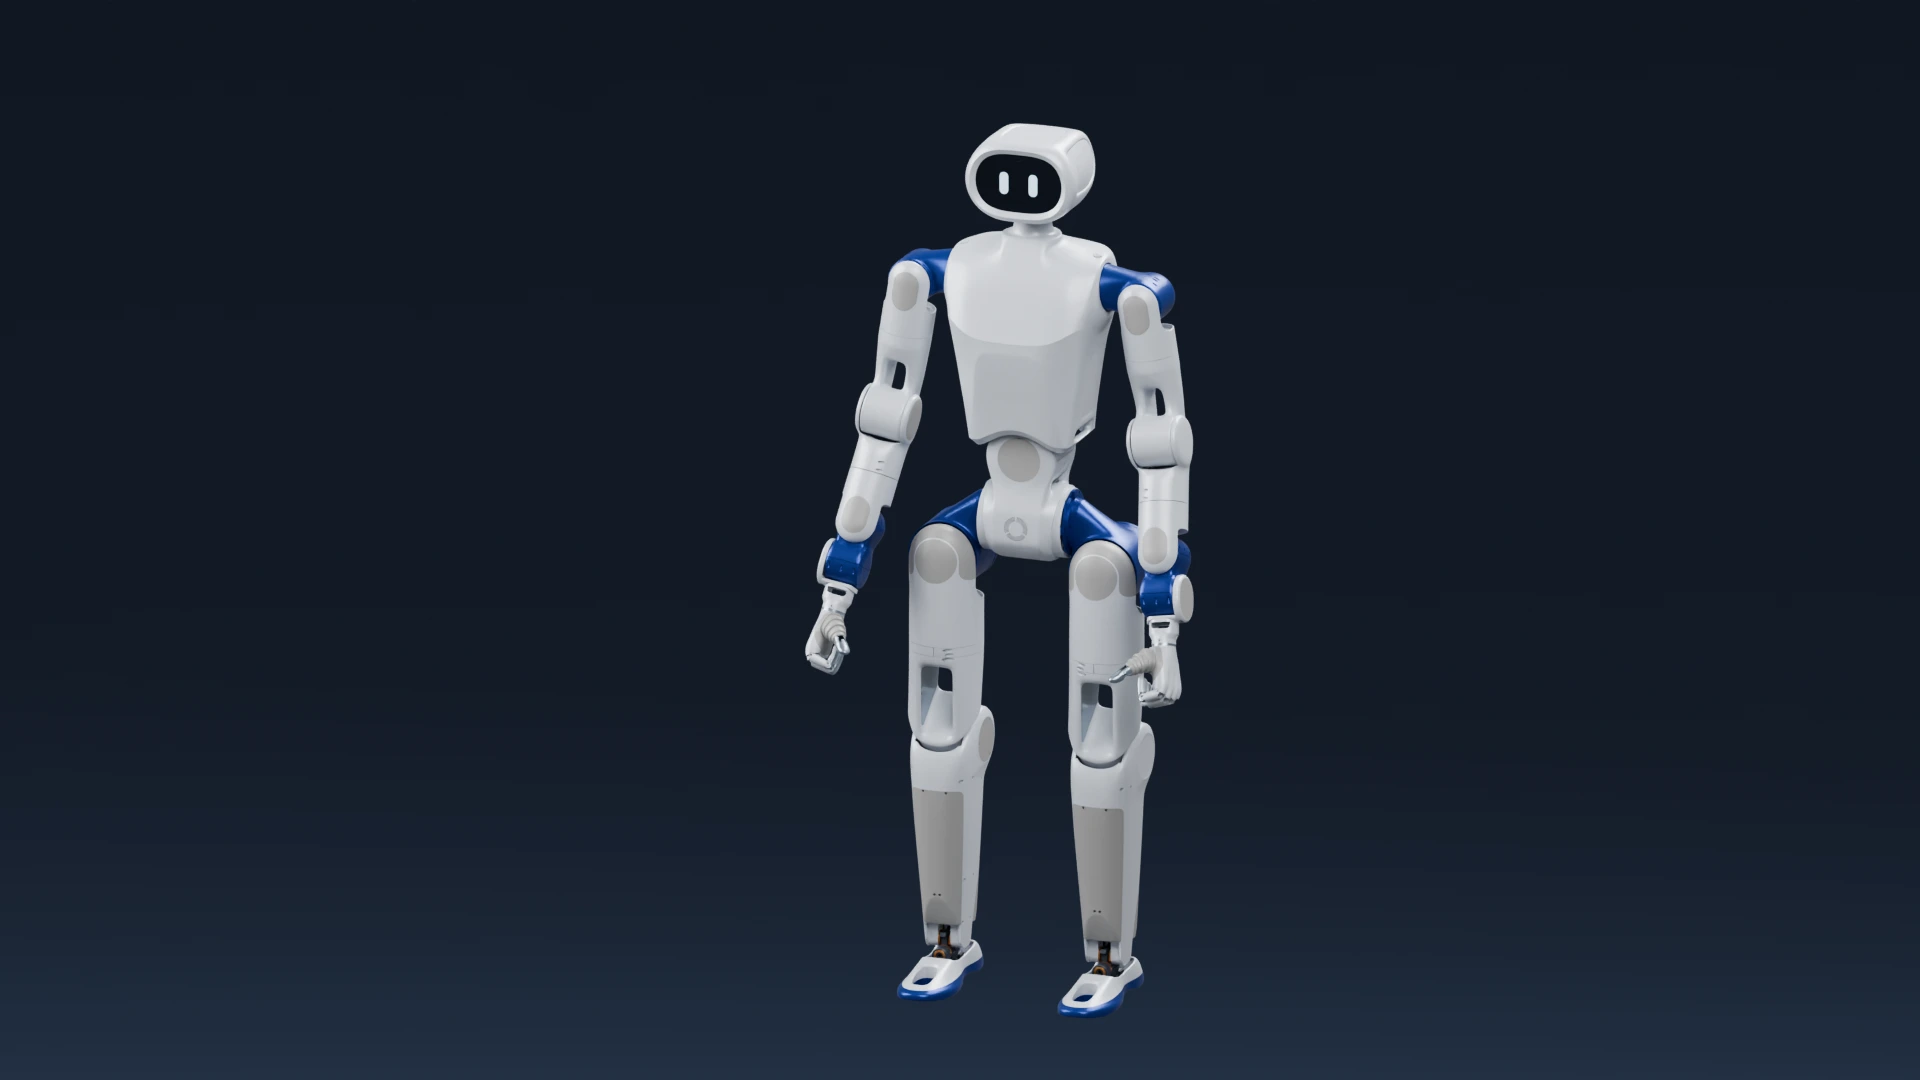
Full-stack open-source humanoid (ROBOTO 01) for researchers and developers: mechanical CAD, PCBs, firmware, models and training code are all published on GitHub.
Renesas' first low-voltage GaN FET family, aimed in part at humanoid robot joint motor drives.


Direct-drive dexterous hand unveiled alongside Flex 2 at the Global Digital Trade Expo.

General-purpose humanoid-style robot with whole-body tactile sensing, launched at IROS 2026.
Next-generation tactile dexterous hand with full-hand e-skin and zero-gap grasping, launched at IROS 2026.

22-DoF exoskeleton data glove with fingertip haptic feedback for teleoperation and dexterous data collection.
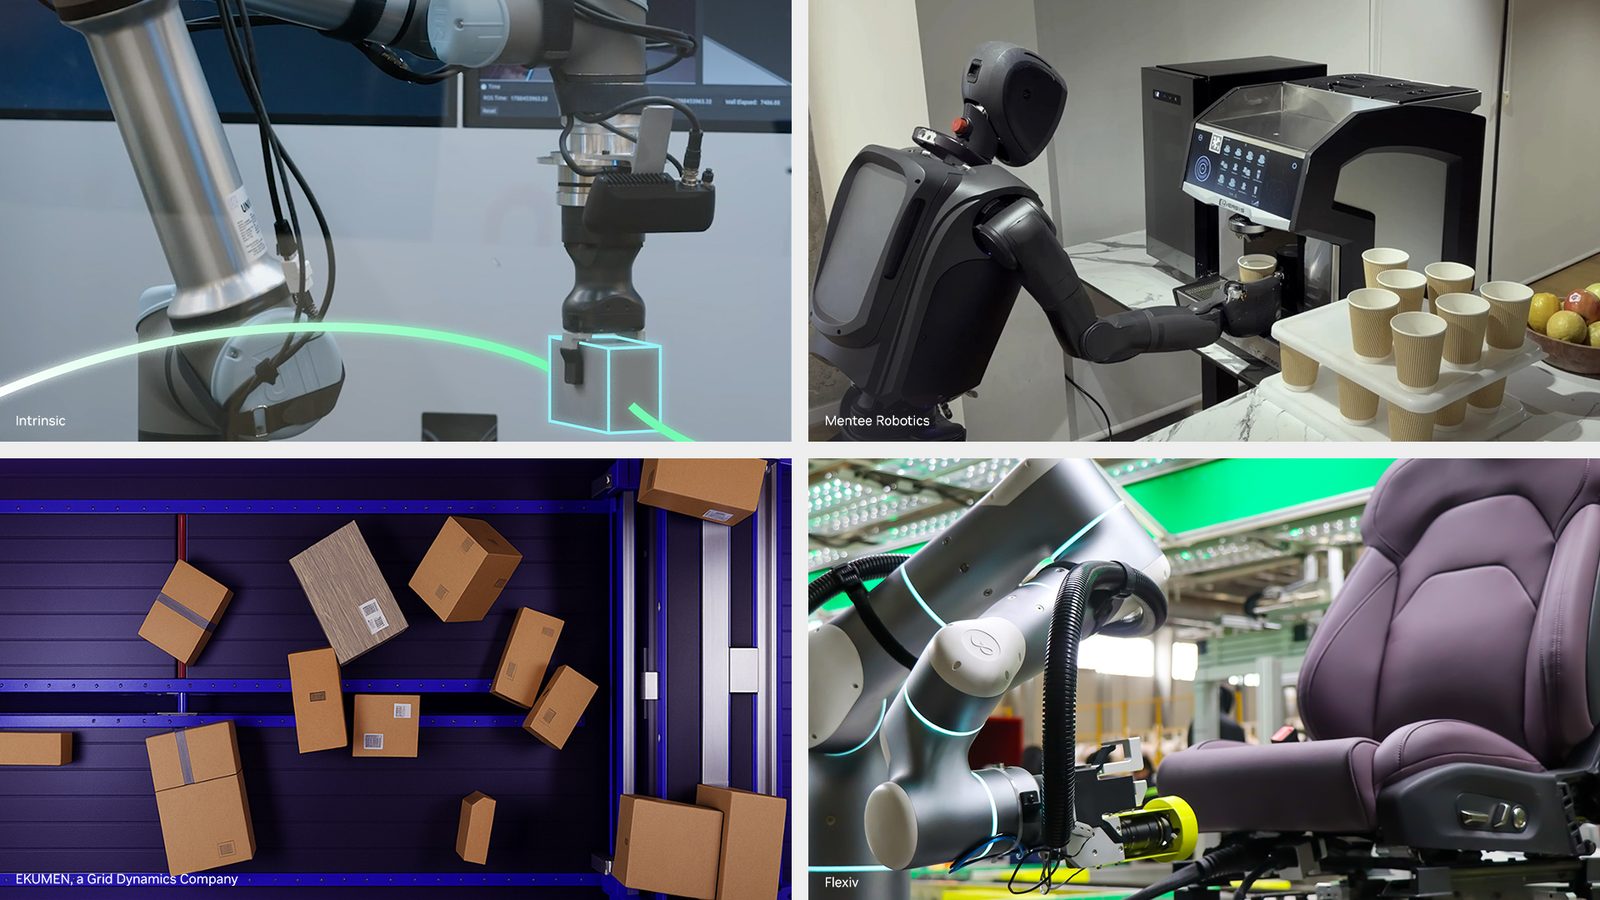

Open-source Isaac ROS release adding agentic workflows, Isaac Skills and GPU-accelerated libraries, announced at ROSCon.
22-DoF human-sized biomimetic dexterous hand with fully backdrivable joints, designed for humanoids like the G1.


Compact, cost-effective 3D LiDAR that keeps the core performance of the Mid-360 series at a lower price for large-scale robot deployment.
Next-generation Digit humanoid engineered for cooperatively safe work near people, with 40% more payload and swappable end-effectors; early access expected H1 2027.

Compact survey-grade 3D lidar series with ultra-small beam spot and high ranging precision for mapping.

UR's seventh-generation cobot platform, launched at IMTS, with three new g-Series arms and an AI-ready tool flange that carries power, data and safety for cameras and sensors.

World Action Model trained from scratch on embodied manipulation data, which AGIBOT presents as validating a pretraining and scaling path for embodied AI.

Open-source embodied foundation model for general-purpose humanoid robots, released by Unitree as a major upgrade of its UnifoLM family.


Next-scale autoregressive world model from X Square Robot for action-controllable, long-horizon robotic simulation.


Compact, lightweight quadruped from MagicLab for inspection and research, with autonomous navigation and open development.
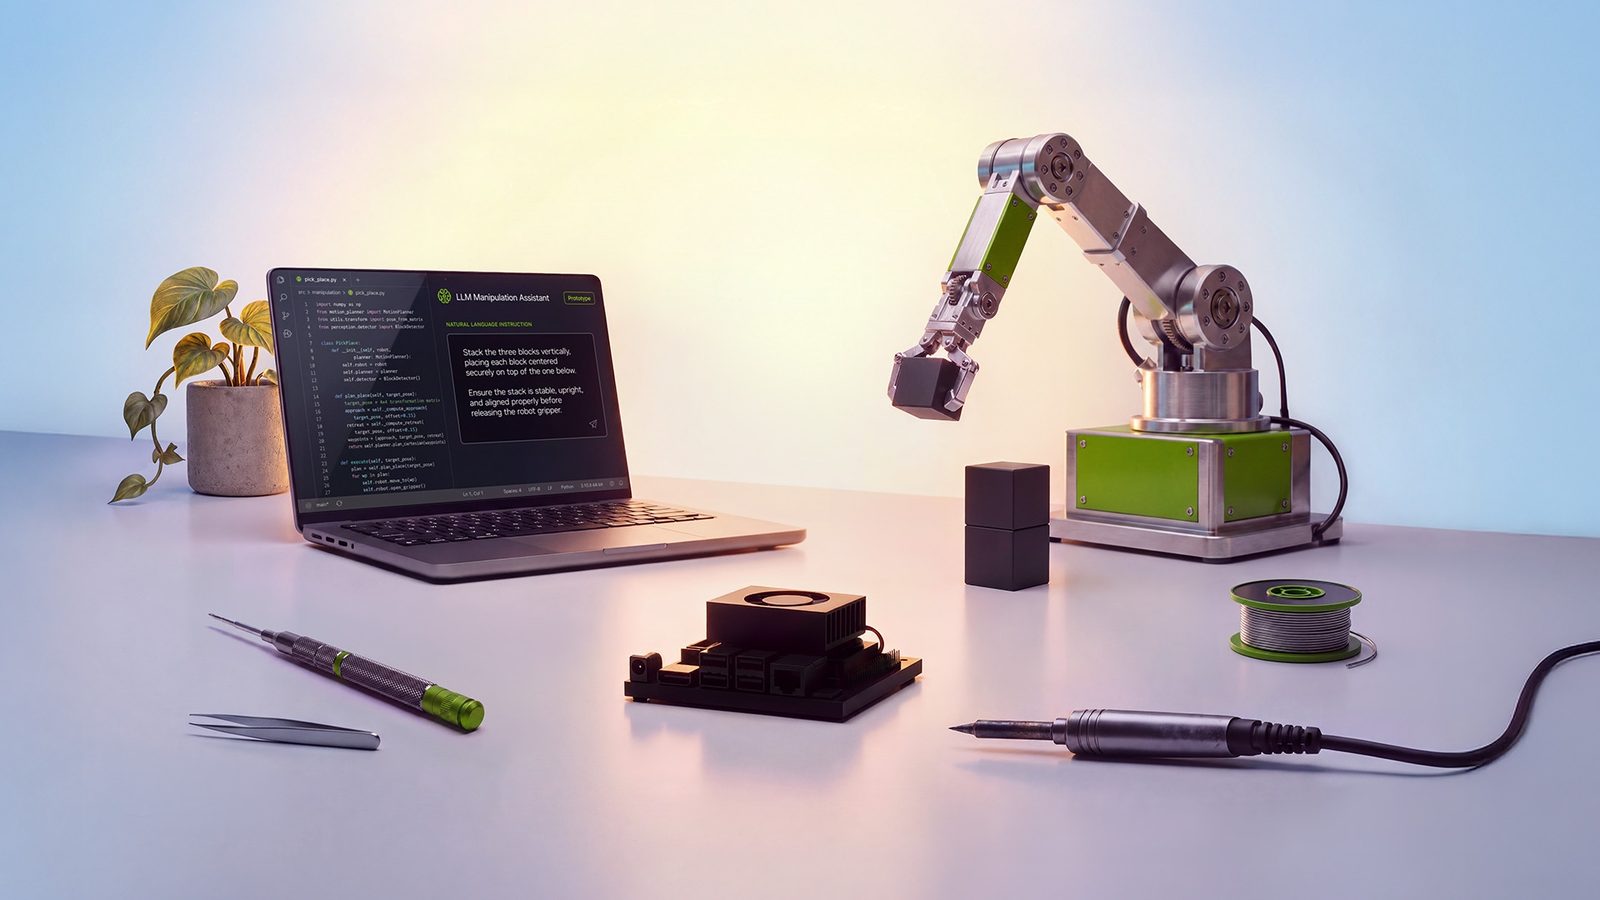
Entry-level edge-AI robotics computer targeting frontier models at lower power.


Foundation model that learns new long tasks from a single example via in-context learning.

AGIBOT's new-generation full-size humanoid, focused on powerful dynamic motion and fast reactions.
Galbot's compact bipedal humanoid for entertainment and performance, debuted at WRC 2026 in Beijing.
One-shot-learning robot foundation model from Generalist that can pick up new tasks in a few seconds from a demonstration.


AI-native pallet-handling robot from Pudu that moves loads of up to 2,000 kg, with rapid deployment and improved obstacle perception.

Release of the Newton physics engine with more parallel simulation, lower memory and consistent contact physics for robot training.


Tactile sensing chip that PaXini calls the world's first true 6D tactile chip, with MHz-rate sampling and on-chip decision-making for full-body touch.


Tactile-grounded world model from Daimon Robotics for robotic dexterity, unifying physical cognition, predictive decision-making and real-time control.

AI-native compact scrubber-dryer robot from Pudu for small commercial spaces such as convenience stores, restaurants, hotels and offices.


World-action model from Dyna Robotics pre-trained on one million hours of human video, with which Dyna reports new scaling laws.

DeepMind's most advanced VLA, extending control from tabletop arms to whole-body humanoids with advanced dexterity and multi-robot teamwork.

Embodied-reasoning model that plans multi-minute tasks, talks with people and coordinates multiple robots, handing off execution to a VLA.
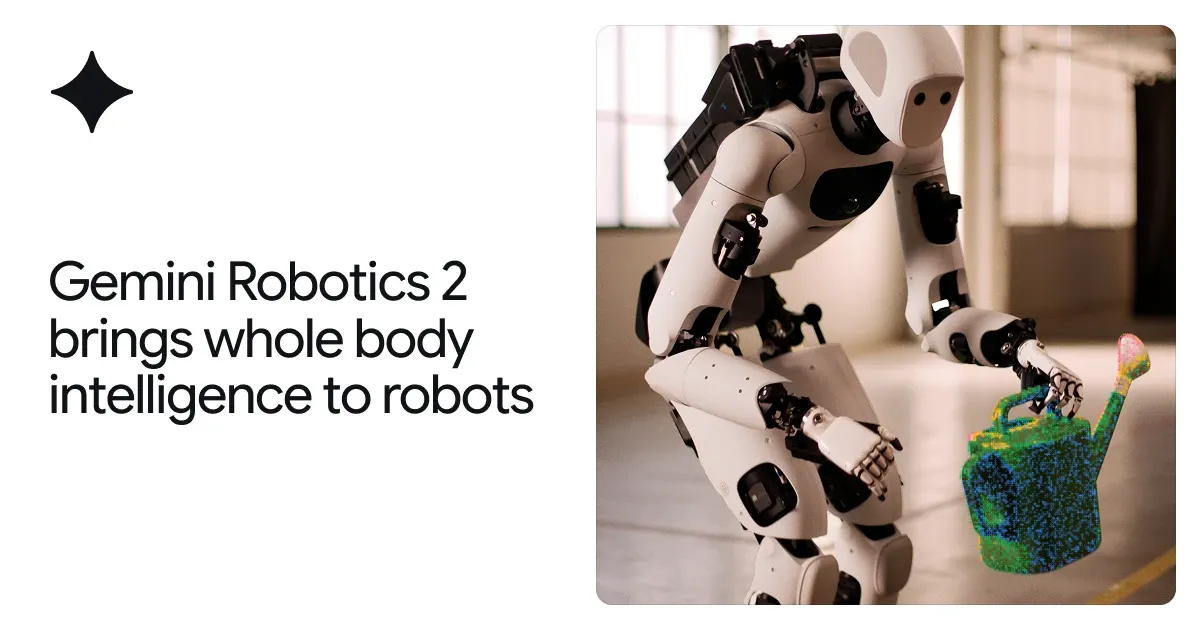
Efficient VLA optimized to run locally on robots, adapting to new embodiments in a few hours.

Ultra-long-range LiDAR from Livox with a 1,000 m maximum cutoff range and dual fields of view for multi-scenario operation.

Wheeled-leg variant of Unitree's AS2 "super athlete" quadruped, supporting a continuous 16 kg payload and 30+ km unloaded driving range.
 Illustration

Italian sensorized humanoid platform with full-body tactile skin and physics-native AI, unveiled as fully functional on 2026-07-20 after a CES 2026 concept reveal; first industrial use case with Finca

Single model for omni-modal, real-time interaction-driven whole-body mobile manipulation on Unitree robots, shown on home-care and wellness tasks.


Preview of Sunday's next robotics model, claimed to work autonomously in unseen homes with no user data.
Compact, more power-efficient Jetson Thor modules extending Blackwell-class compute to mainstream robotics.
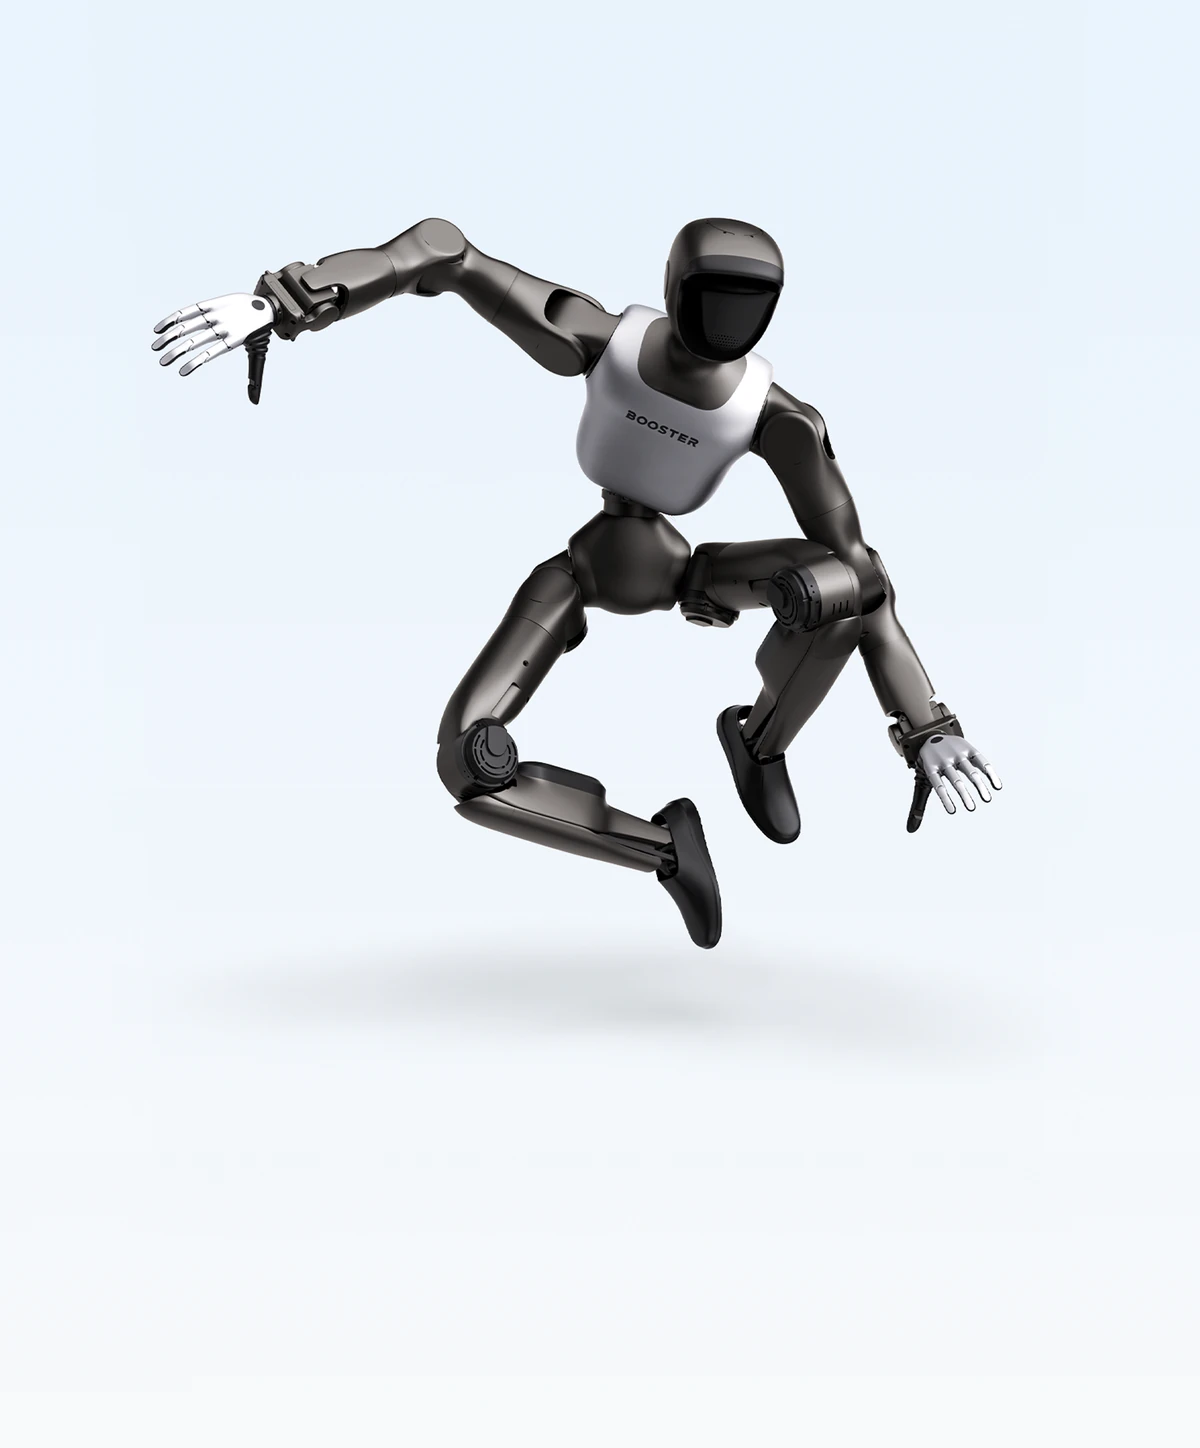
Booster's flagship humanoid development platform with 31 DoF, 375 TOPS onboard compute and an open development ecosystem.


BAAI model presented as an early step toward multimodal latent world models: it learns world latent representations instead of only predicting the next token, frame or action.


First world-model policy in LeRobot: a VLA that also learns action-relevant dynamics by predicting future frames in latent space with a JEPA world model.

LeRobot release closing the robot-learning loop with new policies, unified evaluation benchmarks and a leaner install.

Next-generation UMI-style data-collection kits from X Square Robot in three configurations (Zero-G0, Zero-G1, Zero-E0).

Dexterous hand shown as part of the AGIBOT lineup at WAIC 2026; specs not published in the source post.


First full-size bionic humanoid under UBTECH's new UWORLD consumer brand, introduced at its 2026 Global Launch Event in Shenzhen.


Modular humanoid platform in bipedal and wheeled configurations, used for large-scale data collection at Robot Park with Google DeepMind.

Extension of NVIDIA's Halos safety system to industrial robots, humanoids and AMRs, combining AI compute and functional safety.
AI-native depth camera with an on-camera Gen 5 SoC for humanoids, AMRs and cobots, unveiled at Automate 2026.


Isomorphic pairing of a three-finger data-collection glove and a matching end-effector, which PaXini says is the first mass-producible solution of its kind.

Medical robotic arm from Kinova, engineered from the ground up for the surgery room, weighing under 13 kg with 750 mm reach.

Full-size bionic humanoid series under UWORLD with a memory/emotion AI model and customizable appearance.

Bipedal embodied-AI robot platform from Galaxea, driven by a locomotion "cerebellum" and an embodied AI brain.

Research humanoid reference design built on NVIDIA Isaac GR00T, combining the Unitree H2 body with onboard Jetson Thor compute and Sharpa Wave dexterous hands.

Pudu's new industrial humanoid robot, powered by the PuduFM 1.0 model and designed for real-world manufacturing environments.
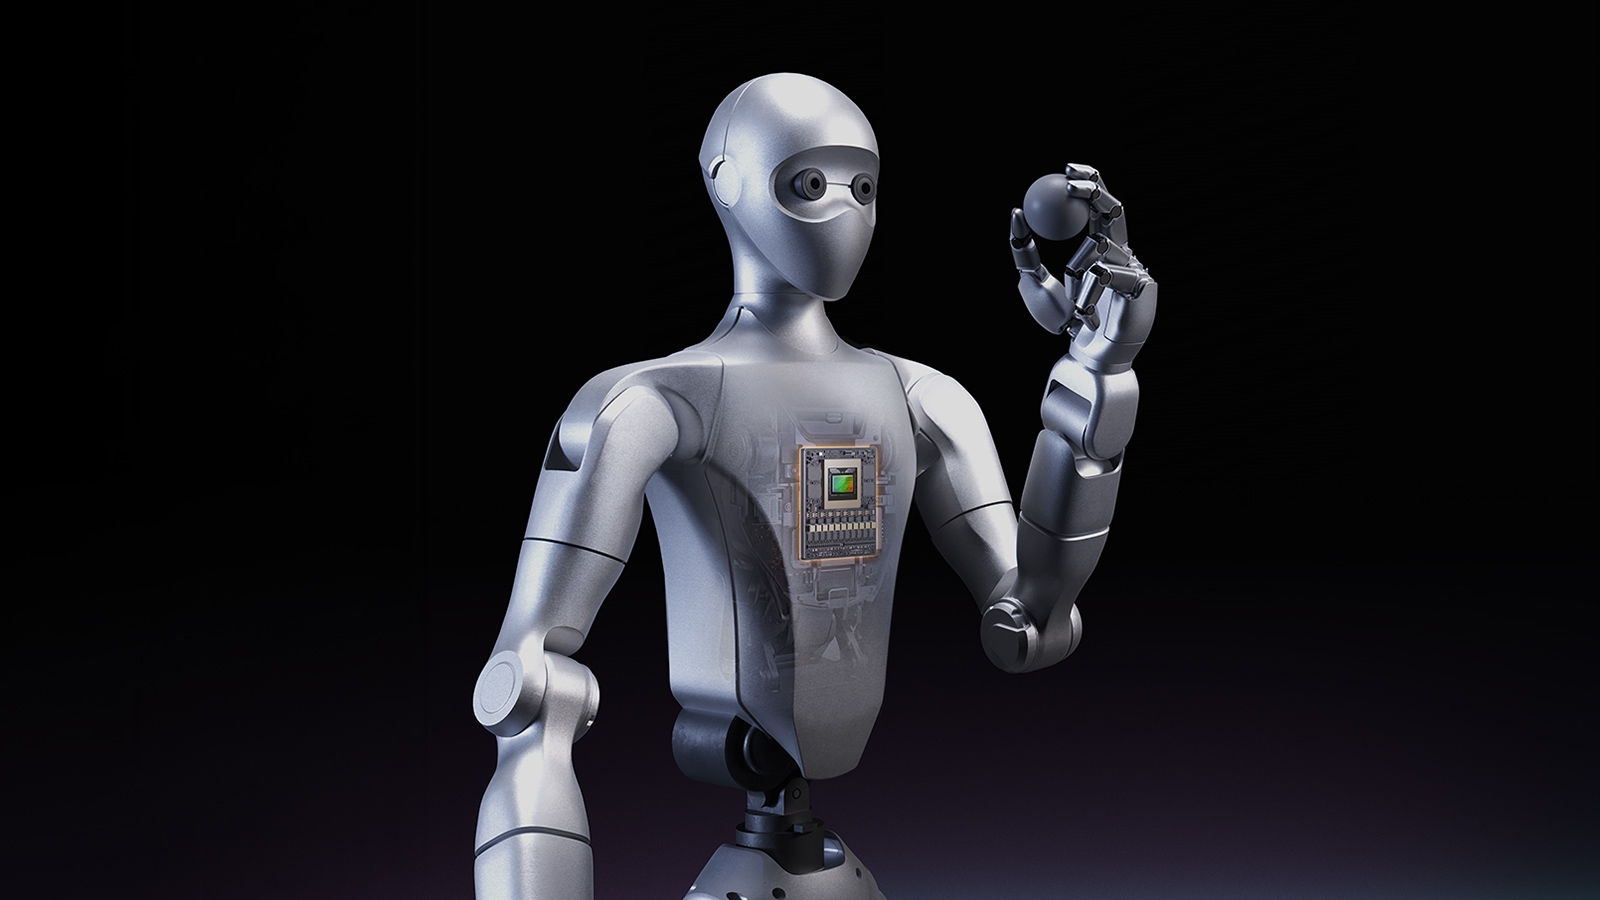
Open humanoid reference design for robotics research that combines the Unitree H2 body, Sharpa Wave dexterous hands and onboard NVIDIA Jetson Thor.


Unified VLA model combining manipulation, navigation and trajectory prediction in one framework (research release).

Open-source world model for embodied AI from X Square Robot, part of its open-source robotics stack alongside WALL-OSS.

Biomimetic quadruped educational robot from Dobot, designed to bring embodied AI into classrooms, labs and research.

Compact sub-20 kg all-terrain robot delivering industry-grade performance in a lightweight form factor.
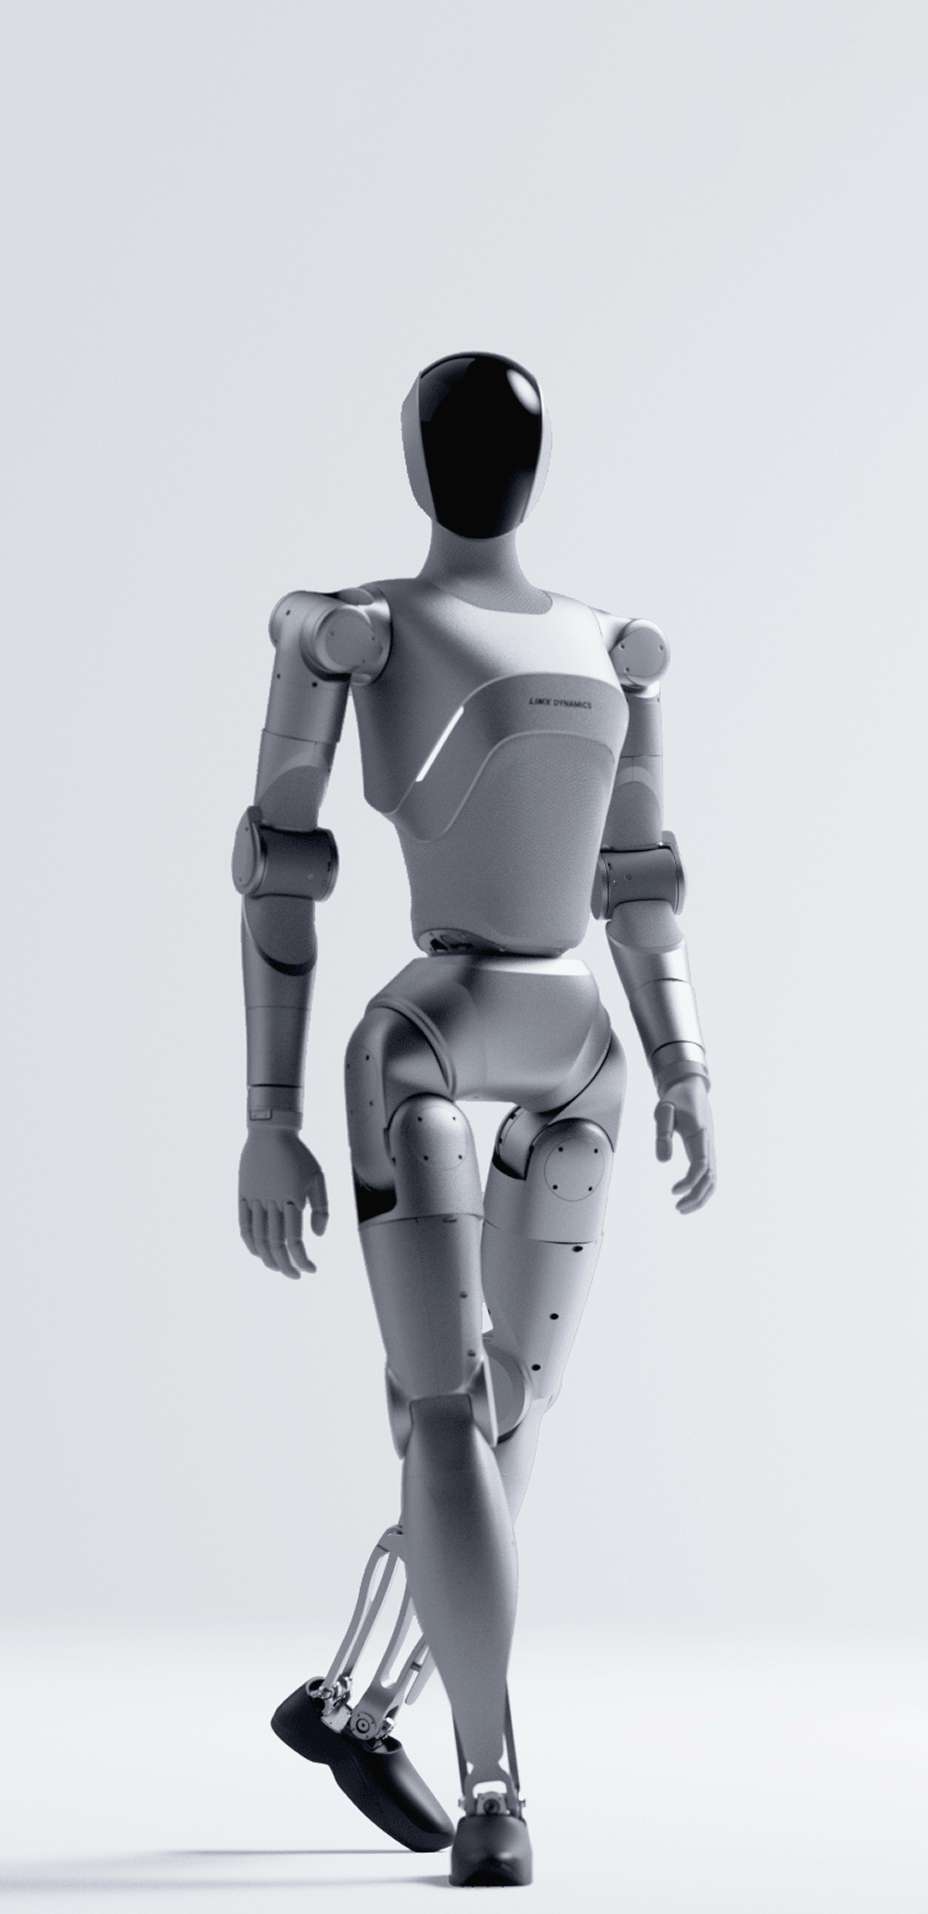

Full-size interactive humanoid designed mainly for commercial performance scenarios, with textile finishes and multimodal interaction.
 Illustration


Unitree's official shared application platform, an app store for humanoid robot tasks and actions that is now open to all users.

Low-cost dual-arm humanoid platform with binocular vision and voice interaction, aimed at fast deployment and task development.

Iterative upgrade of the Lynx M20 wheeled-legged robot with improved load capacity, protection and speed.

Latent world-action foundation model unifying heterogeneous embodied data across sim/real and human/robot sources.

Spatial-intelligence 3D capture platform for collecting high-fidelity real-world data for world models and physical AI; launching later in 2026 per Hesai.

Open-source standardized VLA engineering foundation managing data, training, evaluation, inference and deployment from one config file.

Lower-priced version of the Livox Mid-360 3D LiDAR that Livox says delivers the same performance as its predecessor.

Upgraded embodied-reasoning model with better visual/spatial understanding, instrument reading and safety awareness.

Next-generation AGIBOT foundation model for embodied AI that unifies reasoning and action; revealed during AGIBOT AI Week.

Generalist's robot foundation model, claimed to master simple physical tasks with very little task-specific robot data.

NVIDIA's industrial-grade edge AI platform, now generally available, offering real-time AI performance and functional safety for robots, surgical systems and industrial automation.

Ego-centric data-collection system from AgileX that covers the full pipeline from collection through management and annotation to training.

RealMan dual-arm lift robot and mobile manipulator platform that covers navigation, manipulation and embodied-AI development in one system.

Wheeled humanoid robot from RealMan built for collecting high-quality real-world data.

Ultra-lightweight robot arm in a humanoid configuration, built for natural motion, fast integration and ecosystem compatibility.

Integrated joint modules for high-load robotic applications, offered as WHG-120, WHG-240 and WHG-360 with rated torques of 120, 240 and 360 N·m.

New generation of RealMan integrated joint modules with joint-level force sensing for next-generation robots.

Compact industrial-grade quadruped with a 15 kg payload, 4+ hour runtime and IP54 rating, open for secondary development.

Xiaomi's open-sourced VLA model optimized for smooth real-time execution on consumer GPUs.
Figure's full-body autonomy VLA, demonstrated doing dishes end-to-end with whole-body control.

BAAI embodied-reasoning model that targets two bottlenecks, spatial inaccuracy and temporal instability, with precise 3D spatial reasoning.

Galaxea's 17-DoF four-finger dexterous hand, previewed at CES 2026, with 0.1 N sensitivity and up to 1 kg payload at a single fingertip.
IllustrationEnd-to-end hierarchical VTLA model for fine, last-millimeter manipulation using tactile feedback.
Enterprise-grade electric humanoid unveiled at CES 2026 with autonomous battery swapping; 2026 deployments committed to Hyundai RMAC and Google DeepMind.
Open reasoning vision-language-action model for humanoids, released with NVIDIA's CES 2026 physical-AI model wave.

Open reasoning VLM for physical AI announced at CES 2026 alongside Cosmos Transfer 2.5 and Predict 2.5.

Blackwell-based Jetson Thor-family module bringing real-time robotics inference to a wider range of machines.

Premium robotics processor for advanced AMRs and full-size humanoids, launched at CES 2026 with an end-to-end physical-AI stack.

Collaborative system for large-scale robot policy evaluation in simulation, co-developed with Lightwheel.
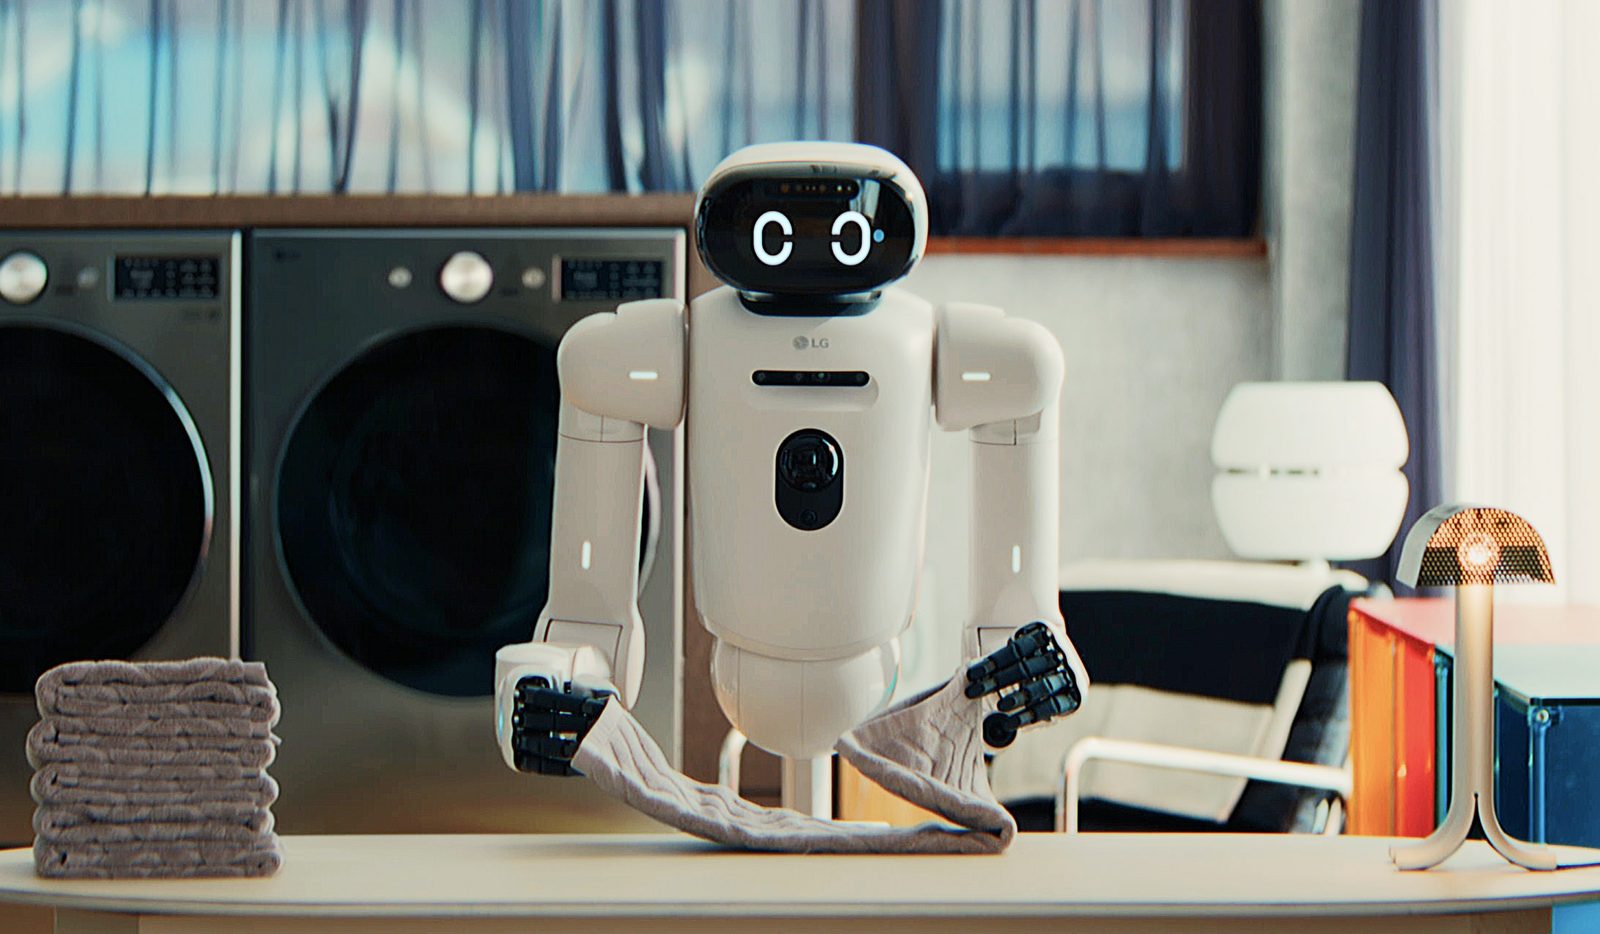
Wheeled AI home robot shown at CES 2026 demonstrating chores such as laundry folding and breakfast prep under LG's "Zero Labor Home" vision.

Foundation VLA for bimanual dexterous manipulation pretrained on egocentric human and robot data.
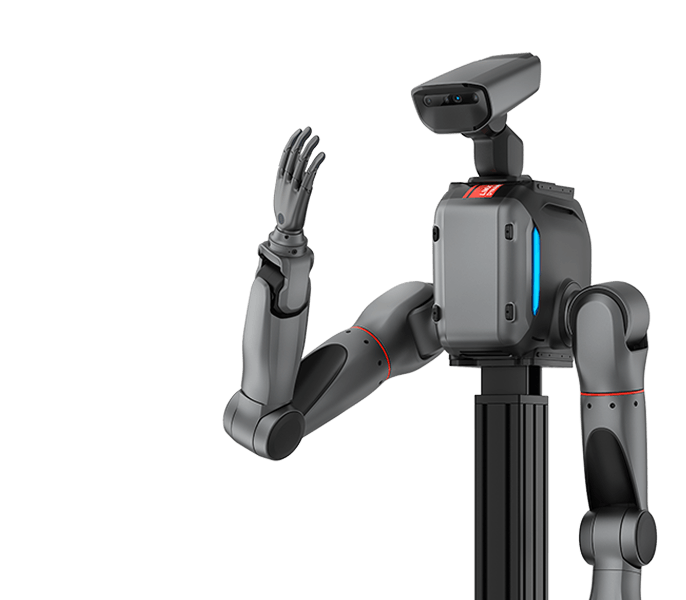
Modular multi-form embodied robot that switches between dual-arm, bipedal and wheel-legged configurations, positioned as a VLA development platform.

Soft-prompted VLA in LeRobot that scales across robots, cameras and action spaces with one transformer backbone.

Industry-grade autonomous quadruped series built for tough, unstructured and dynamic environments.


Full-size high-torque general-purpose humanoid offered in Basic, Open Source, Pro and Max editions.

Lightweight 7-DoF arm for embodied-AI and humanoid research, with drag-to-teach, API control and compatibility with AgileX mobile bases.
Wheeled two-armed home robot that clears tables, loads dishwashers and folds socks; Founding Family beta planned for late 2026.
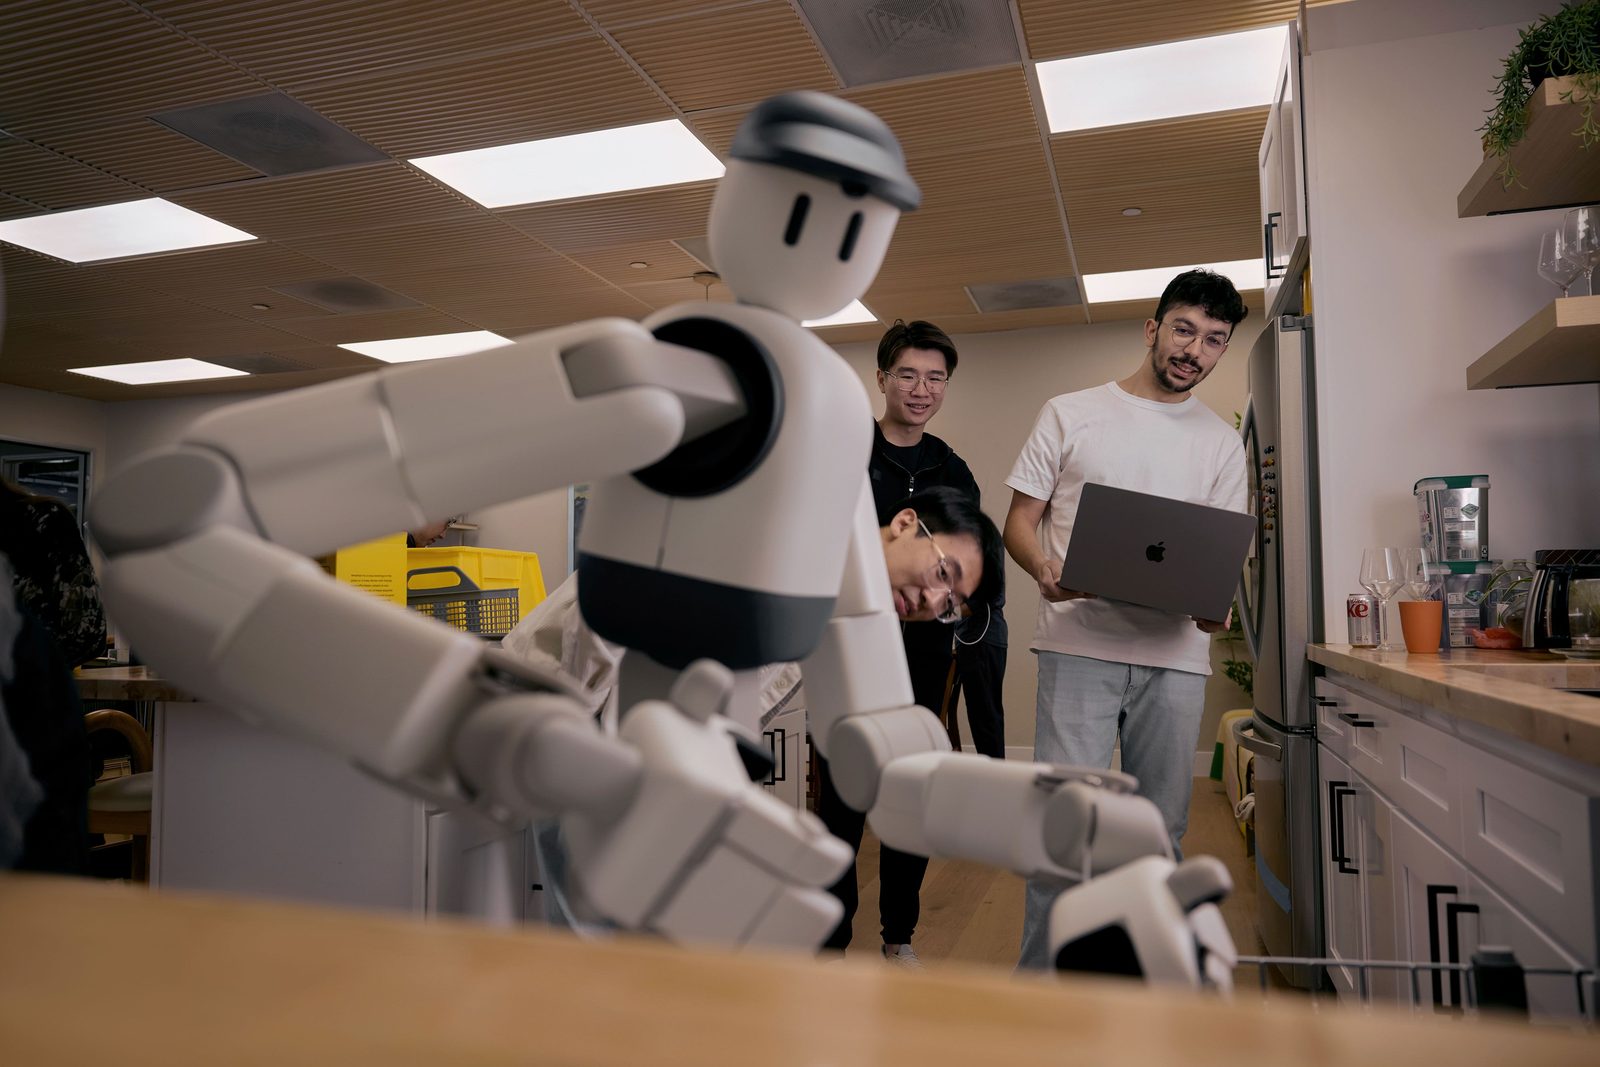
Sunday's robot foundation model trained without teleoperation data, powering Memo's long-horizon household tasks.
VLA that learns from its own experience via RL, demonstrated making espresso, folding laundry and assembling boxes for hours.

Cross-embodiment, cross-task navigation foundation model with 360° perception and vision-only obstacle avoidance.


Next-gen IRON humanoid with bionic spine, artificial muscles and flexible skin, unveiled at XPENG Tech Day with mass production targeted for 2026.

Generalist's 10B+ parameter robot foundation model, built on a "Harmonic Reasoning" architecture and trained on more than 270,000 hours of dexterous data.
 Illustration
Unitree's first wheeled humanoid, an end-to-end platform for data collection and model training with optional grippers or dexterous hands.

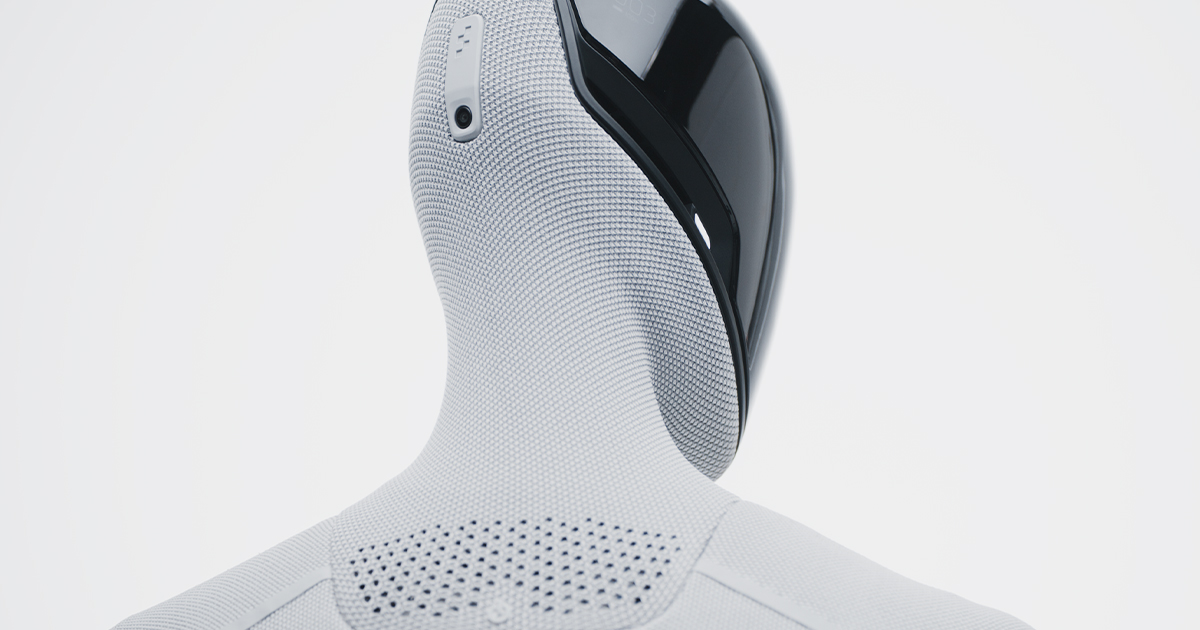
Consumer home humanoid with tendon-driven actuation and a soft lattice-polymer body, available for pre-order with US deliveries starting in 2026.
Major open-source LeRobot release with chunked Dataset v3.0 and integration of NVIDIA GR00T N models.

Full-size 180 cm bionic humanoid from Unitree with 31 DoF and a bionic face, aimed at research, interaction and service applications.
Compact introductory humanoid for embodied-AI development with Python/C++ SDKs and ready-to-use agents.
IllustrationNew-generation industrial interactive embodied robot built to industrial standards.

All-weather humanoid robot from quadruped maker DEEP Robotics, built for agility and real-world outdoor scenarios.
No launches match these filters.