Image: cdn.sanity.io
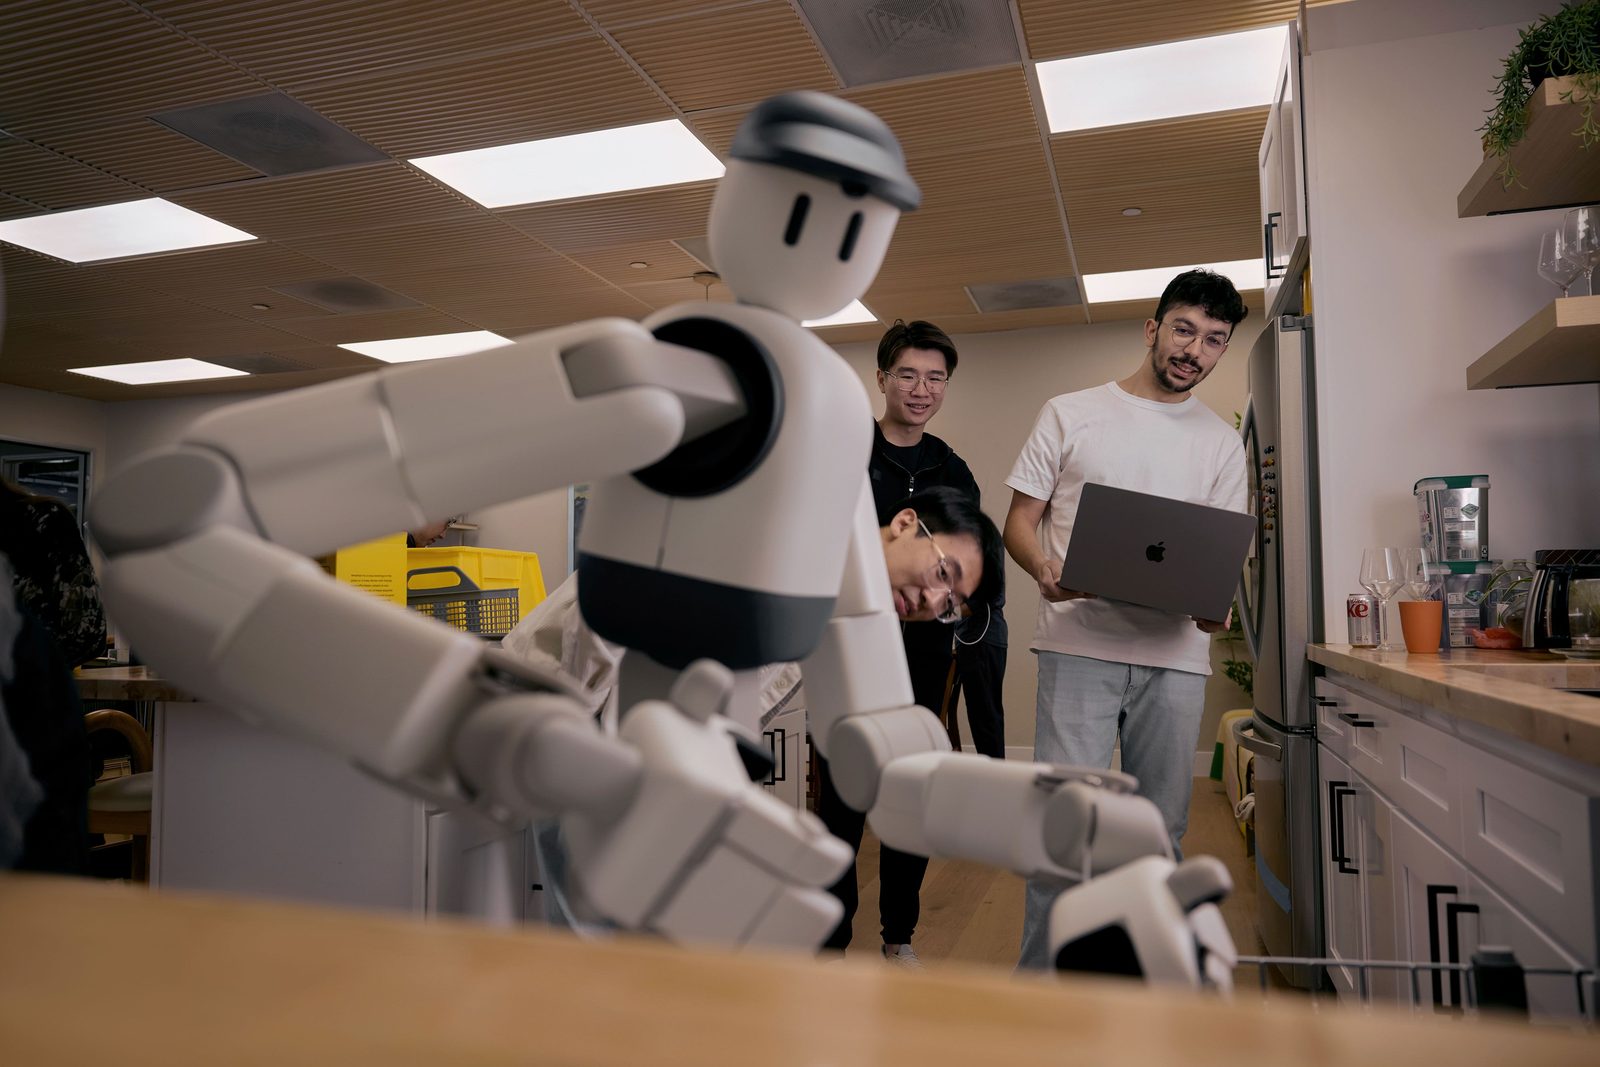
Sunday's robot foundation model trained without teleoperation data, powering Memo's long-horizon household tasks.
Key specs
| Training data | Zero robot teleop data; Skill Capture Glove data |
|---|
Technical details
ACT-1 is Sunday's first robot foundation model, trained without any teleoperation data. Sunday co-designed the Skill Capture Glove to match Memo's hand geometry and sensors, and uses Skill Transform to align kinematic and visual observations so glove recordings become robot-equivalent training data (90% conversion success). ACT-1 performs an ultra-long-horizon table-to-dishwasher task (33 unique and 68 total dexterous interactions with 21 objects, over 130 ft of navigation) and generalizes zero-shot to unseen homes by conditioning on 3D maps. Sunday describes it as the first foundation model to combine long-horizon manipulation and map-conditioned navigation end to end.
| Architecture | End-to-end robot foundation model combining long-horizon manipulation with map-conditioned navigation (conditioned on 3D maps of the environment). |
|---|---|
| Inputs outputs | Inputs: robot observations plus a 3D map of the home; outputs: whole-body mobile-manipulation actions for Memo, from millimeter-level manipulation to room-scale navigation. |
| Training data | Zero robot teleoperation data: human data captured with the Skill Capture Glove (same geometry and sensor layout as Memo's hand), converted to robot-equivalent data by Skill Transform (90% conversion success). |
| Embodiments supported | Sunday Memo. |
| License weights | Proprietary; not released. |
| Sources |