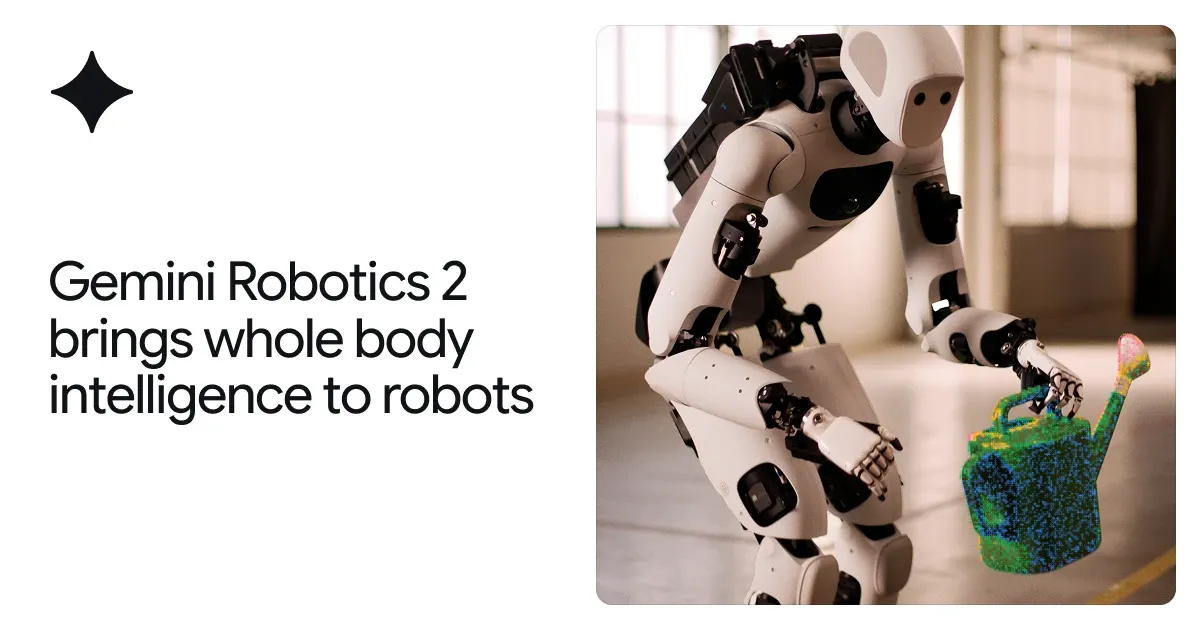
Image: lh3.googleusercontent.com
Efficient VLA optimized to run locally on robots, adapting to new embodiments in a few hours.
Key specs
| Product type | On-device VLA |
|---|---|
| Adaptation | New embodiments with a few hours of data |
Technical details
Gemini Robotics On-Device 2 is DeepMind's most efficient VLA, built to run locally on robots where latency or connectivity rule out cloud inference. It is natively multi-embodiment and reuses motion-transfer techniques from Gemini Robotics 1.5, adapting to new bi-arm embodiments in a few hours, typically with fewer than 200 examples. DeepMind demonstrates adaptation to embodiments with very different shapes, sensors and DoF (Dexmate, SO101, Trossen). Access is limited to early-access partners.
| Architecture | Efficiency-optimized vision-language-action model designed to run locally on robots; natively multi-embodiment, inheriting 'motion transfer' techniques from Gemini Robotics 1.5. |
|---|---|
| Inputs outputs | Inputs: vision + language; outputs: robot actions, computed on-device without network connectivity. |
| Training data | Adaptation to new bi-arm embodiments typically uses fewer than 200 examples (a few hours of adaptation). |
| Embodiments supported | Bi-arm robots, demonstrated on Dexmate, SO101 and Trossen platforms. |
| License weights | Proprietary; available to early-access partners. |
| Hardware requirements | Runs locally on robotic devices (specific compute not disclosed). |
| Sources |