Image: blogs.nvidia.com
Open-source Isaac ROS release adding agentic workflows, Isaac Skills and GPU-accelerated libraries, announced at ROSCon.
Key specs
| Support | ROS 2 Lyrical; Jetson Orin Nano to Thor |
|---|
Technical details
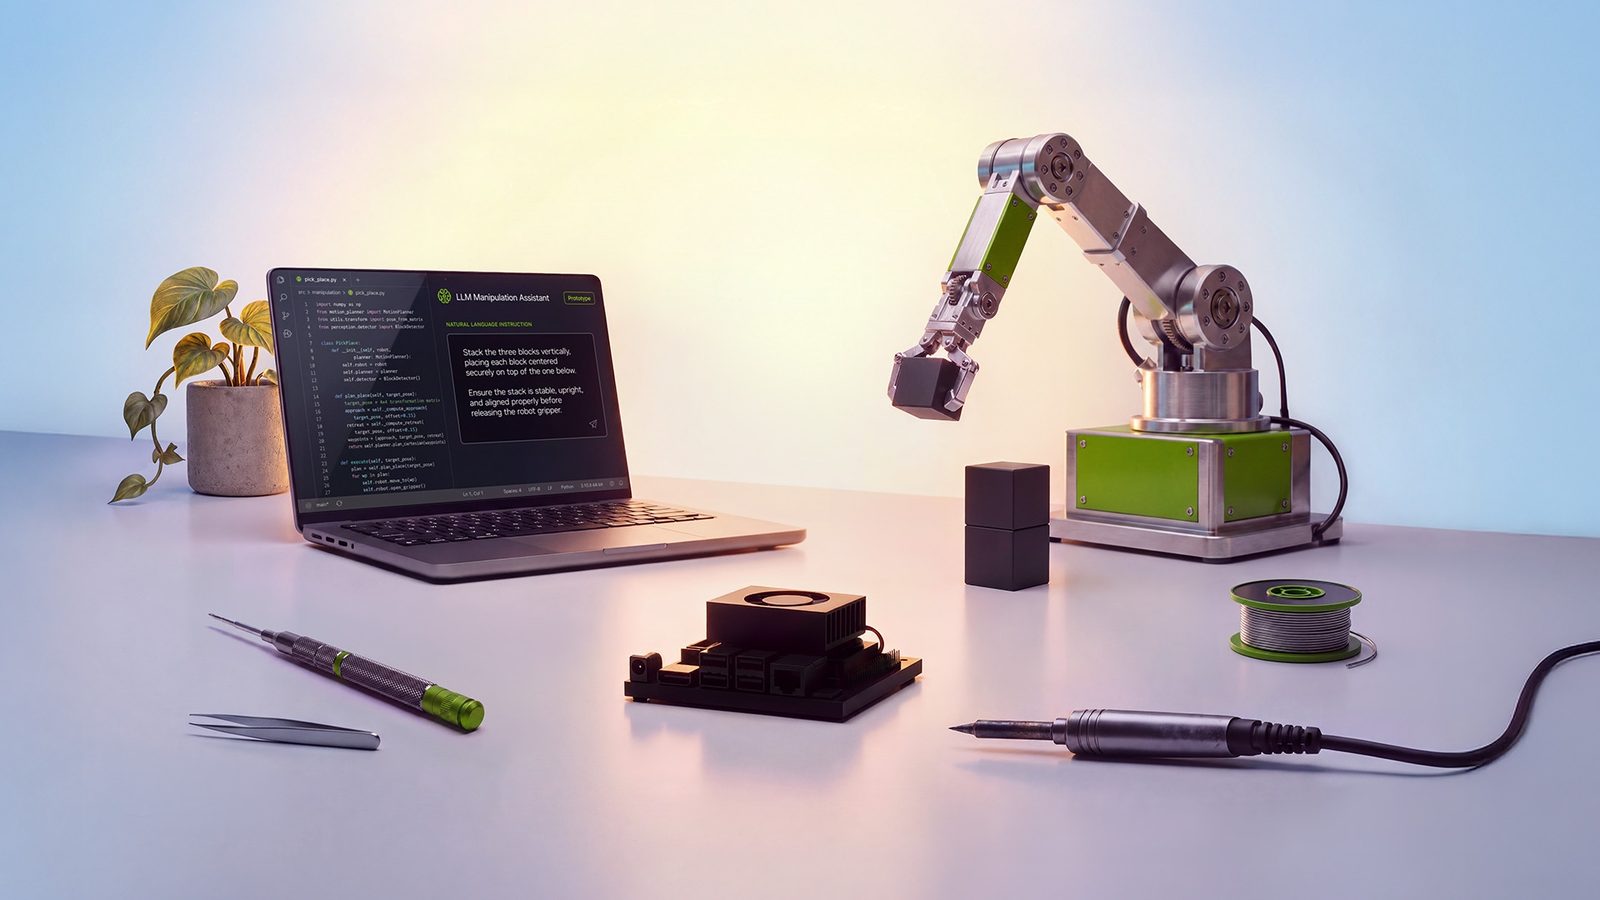
Isaac ROS 5.0 is NVIDIA's open-source set of GPU-accelerated ROS 2 packages, released at ROSCon 2026 with support for ROS 2 Lyrical and Ubuntu 24.04. NVIDIA worked with the Open Source Robotics Alliance to contribute a standard data-handling interface to ROS Lyrical so robotics software can run efficiently across compute hardware, with CUDA as the reference GPU implementation. New agent-ready Isaac skills cover setup, FoundationStereo fine-tuning, a FoundationPose inference library (up to 5.5x faster) and a standalone pick-and-place pipeline. It targets deployment on Jetson Orin Nano through Jetson Thor.
| Architecture | Collection of GPU-accelerated ROS 2 packages (CUDA-accelerated perception, manipulation, motion planning) plus agent-ready 'Isaac skills' and documentation for AI-assisted development; contributes a standard hardware-agnostic data-handling interface to ROS Lyrical. | ||||||
|---|---|---|---|---|---|---|---|
| Inputs outputs | Robot sensor streams (e.g. stereo/depth cameras) in; accelerated perception outputs (depth, object pose/tracking, collision-free motion plans) out, via standard ROS 2 interfaces. | ||||||
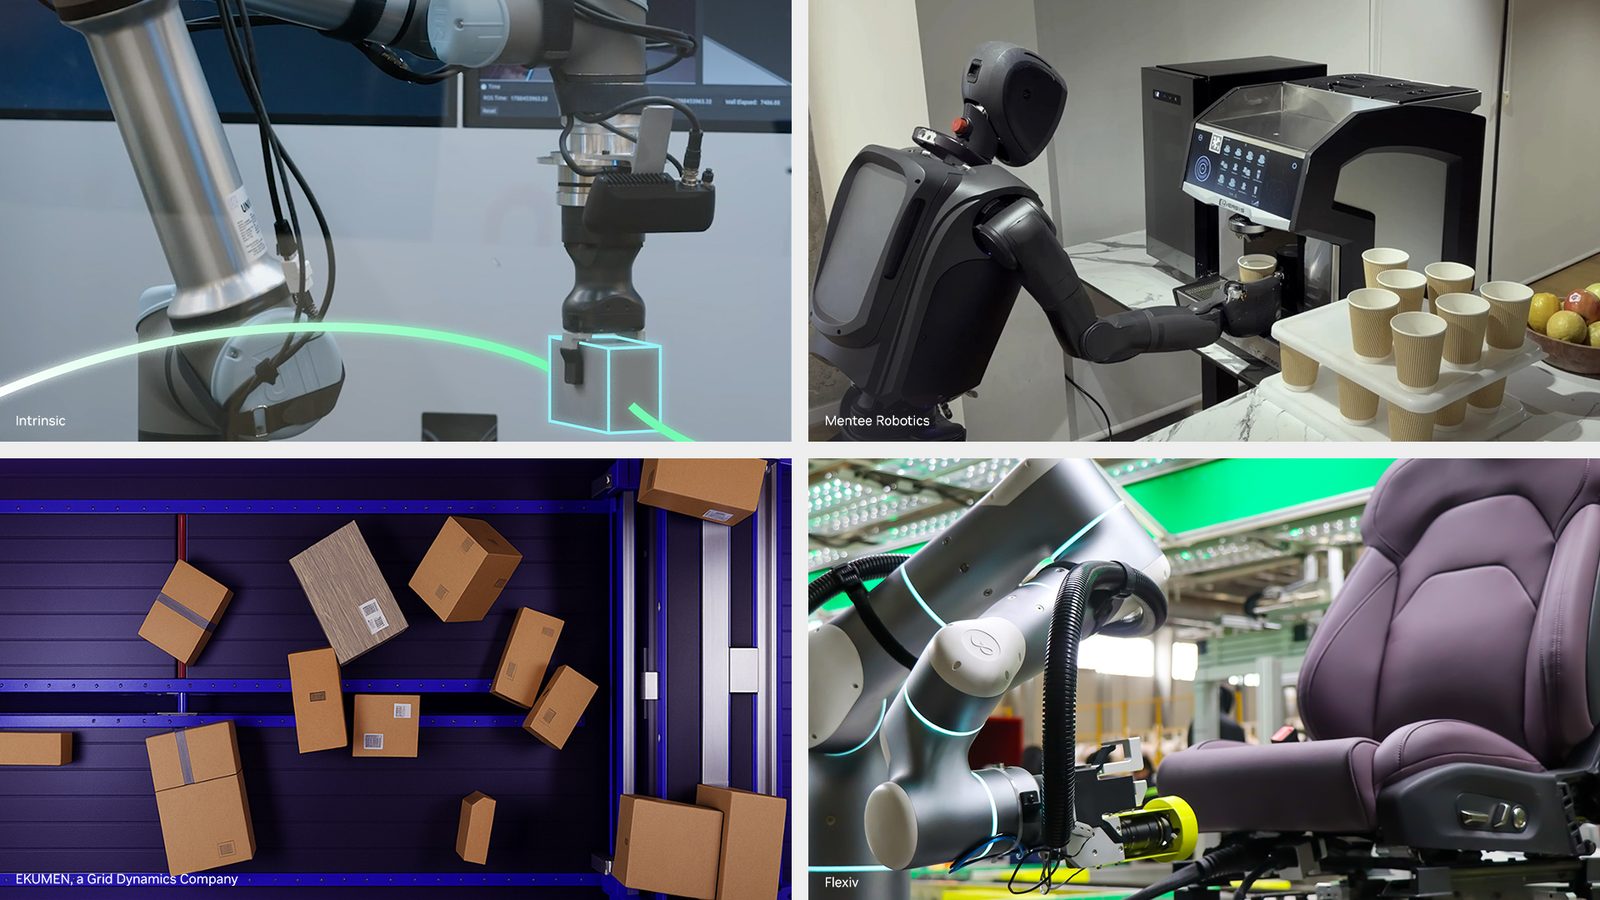
| Embodiments supported | Any ROS 2 robot; partner integrations cited include Flexiv Rizon 4, Universal Robots, ROBOTIS AI Worker, Seeed reBot Arm and the MenteeBot humanoid. | ||||||
| License code | Free and open source per NVIDIA (see individual NVIDIA-ISAAC-ROS repository licenses). | ||||||
| Hardware requirements | ROS 2 Lyrical on Ubuntu 24.04; NVIDIA Jetson from Jetson Orin Nano up to Jetson Thor (plus NVIDIA GPUs). | ||||||
| Benchmarks claimed |
| ||||||
| How to try | github.com/NVIDIA-ISAAC-ROS | ||||||
| Sources |