Image: images.ctfassets.net
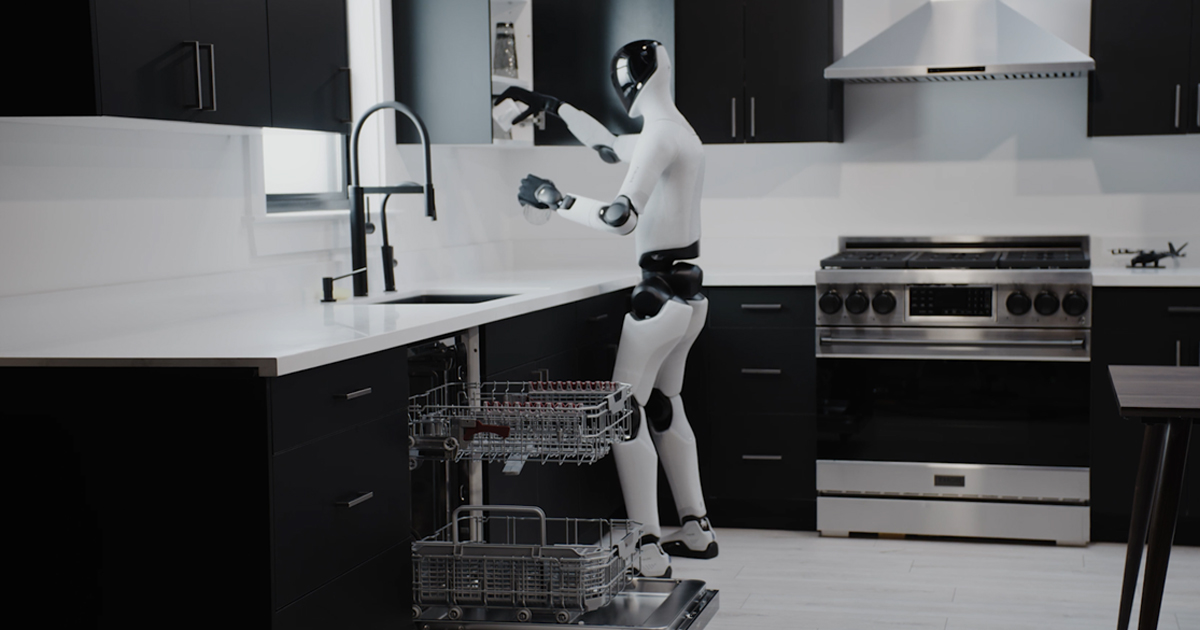
Figure's full-body autonomy VLA, demonstrated doing dishes end-to-end with whole-body control.
Key specs
| Architecture | Adds System 0 learned whole-body controller |
|---|---|
| Training data | 1,000+ hours of human motion data plus sim |
Technical details
Helix 02 extends Figure's System 1/System 2 VLA with a new System 0, a 10M-parameter learned whole-body controller running at 1 kHz that replaces 109,504 lines of hand-engineered C++. System 1 now maps all sensors (head and palm cameras, fingertip tactile, proprioception) to full-body joint targets at 200 Hz, while System 2 sequences semantic latent goals from language. Figure demonstrates a 4-minute autonomous dishwasher unload/reload across a kitchen with 61 loco-manipulation actions, plus tactile-dependent dexterity such as pill extraction and dispensing 5 ml from a syringe. S0 is trained on 1,000+ hours of human motion and sim RL across 200k+ parallel environments.
| Architecture | Hierarchical VLA: System 2 (slow VLM for scene/language understanding producing latent goals), System 1 (transformer visuomotor policy producing full-body joint targets at 200 Hz) and System 0 (learned whole-body controller at 1 kHz). |
|---|---|
| Params | System 0: 10M parameters (S1/S2 sizes not disclosed) |
| Inputs outputs | Inputs: head cameras, palm cameras, fingertip tactile sensors, full-body proprioception, language; outputs: joint-level control of legs, torso, head, arms, wrists and individual fingers. |
| Training data | System 0 trained on 1,000+ hours of joint-level retargeted human motion data and sim-to-real RL across 200,000+ parallel simulated environments with domain randomization. |
| Embodiments supported | Figure 03 humanoid (tactile fingertips, palm cameras). |
| License weights | Proprietary; not released. |
| Hardware requirements | Onboard Figure robot compute. |
| Sources |